
Vanguard Robotics / ESTUN integration partner
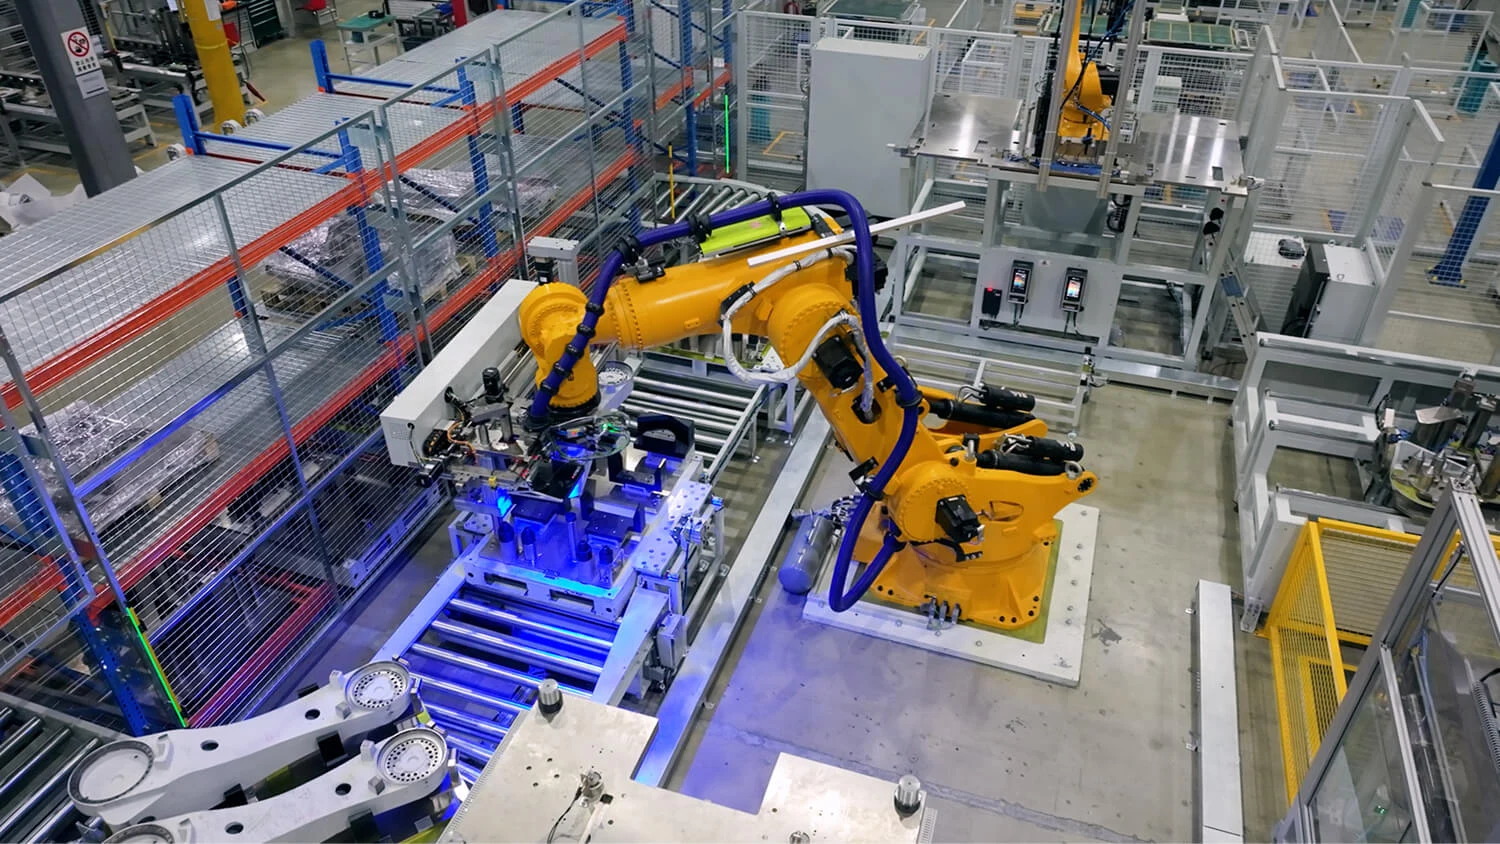
Robot cell integration
Specify and integrate the robot, tooling, automation and equipment that make up your cell.
Your starting point
Robot cell integration
For a site with a defined operation to automate that needs an integrator to manage equipment and interfaces.
Scope to agree
Define mechanical, electrical and software scope and site interfaces.
Size the arm, gripper, supports and agreed peripherals.
Coordinate risk assessment and validation with the designated contributors.
Program sequences, install and test the cell with your parts.
Prepare the work
Information to share with us.
- Specification, representative parts and inspection criteria.
- Layout, utilities and upstream and downstream machine interfaces.
- Installation window, production organisation and validation owners.
Acceptance and limitations
Trials follow a protocol agreed before implementation. It specifies formats, cycle, fault cases and expected results. Deviations and outstanding items are recorded.
The quotation distinguishes equipment supply, integration, trials and services after commissioning. Open points remain identified.
Applications
Connect the service to your process.
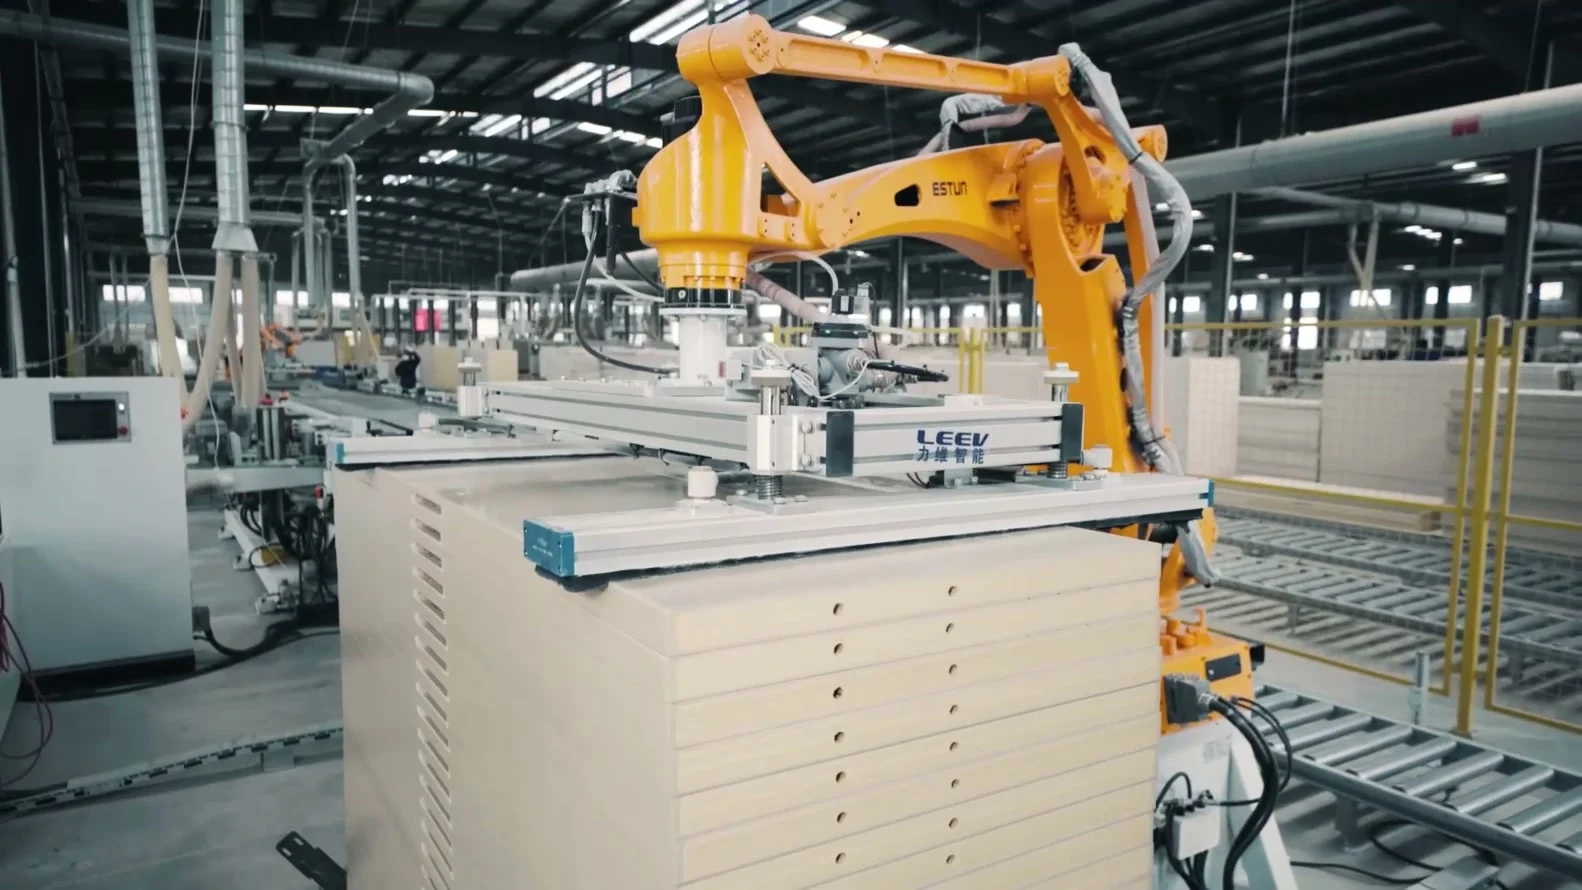
Palletising and depalletising
Stack cases, bags or totes at the end of the line. The project connects the gripper, conveyors and pallet patterns to your production requirements.
Information and trials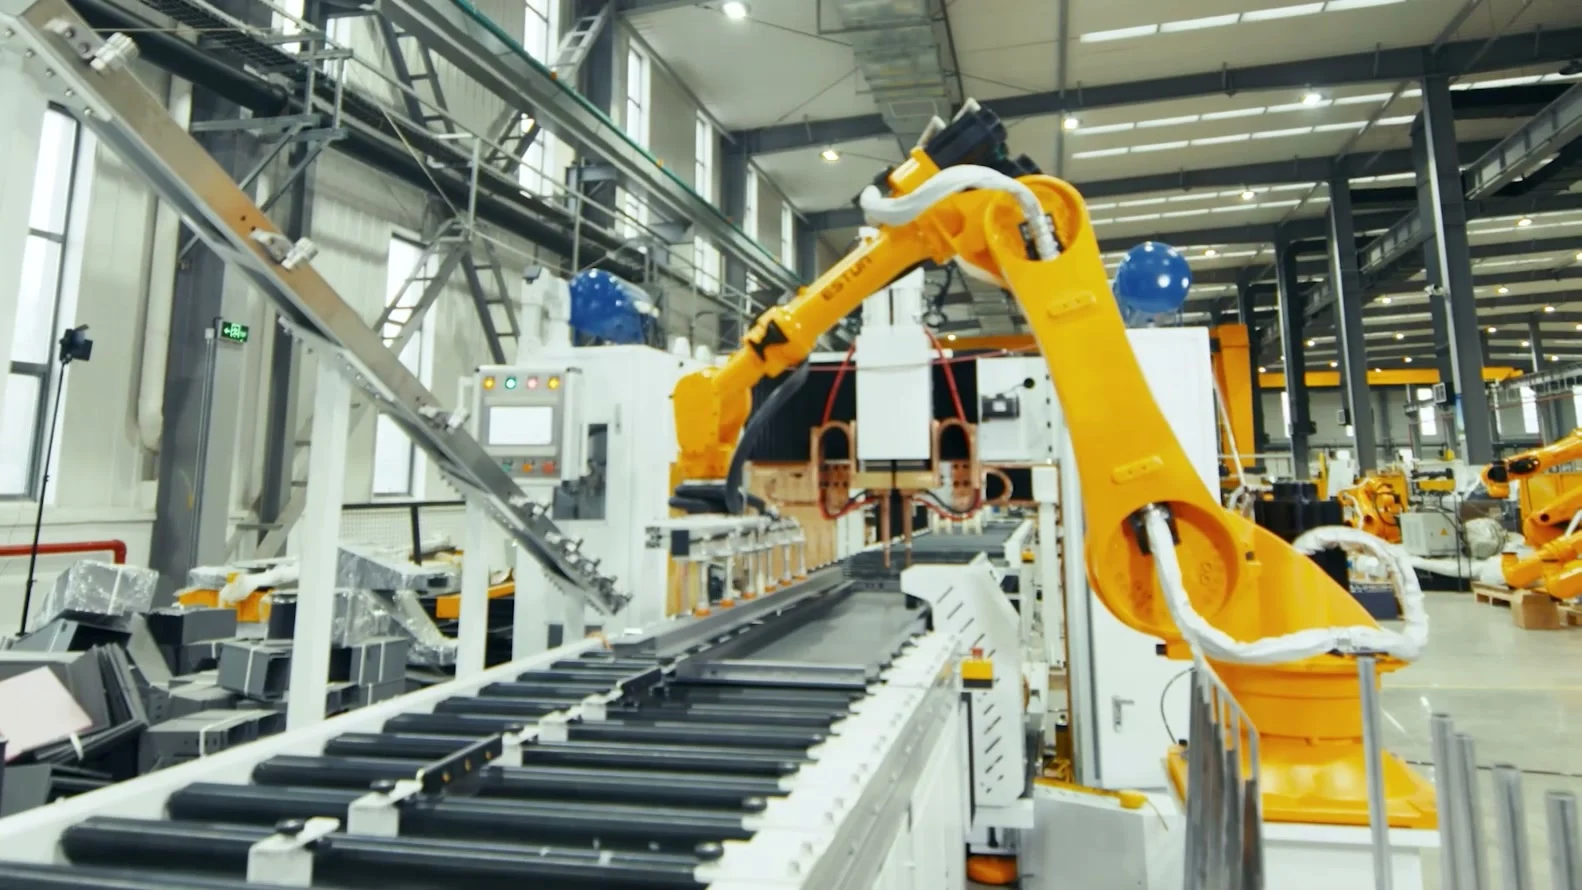
Machine tending
Load and unload a machining centre, lathe or another production machine. The cell coordinates part gripping, doors, clamping and machine states.
Information and trialsRobotic welding
Repeat weld seams on fixtured parts. Integration combines the robot, torch, power source and positioner with the selected welding process.
Information and trials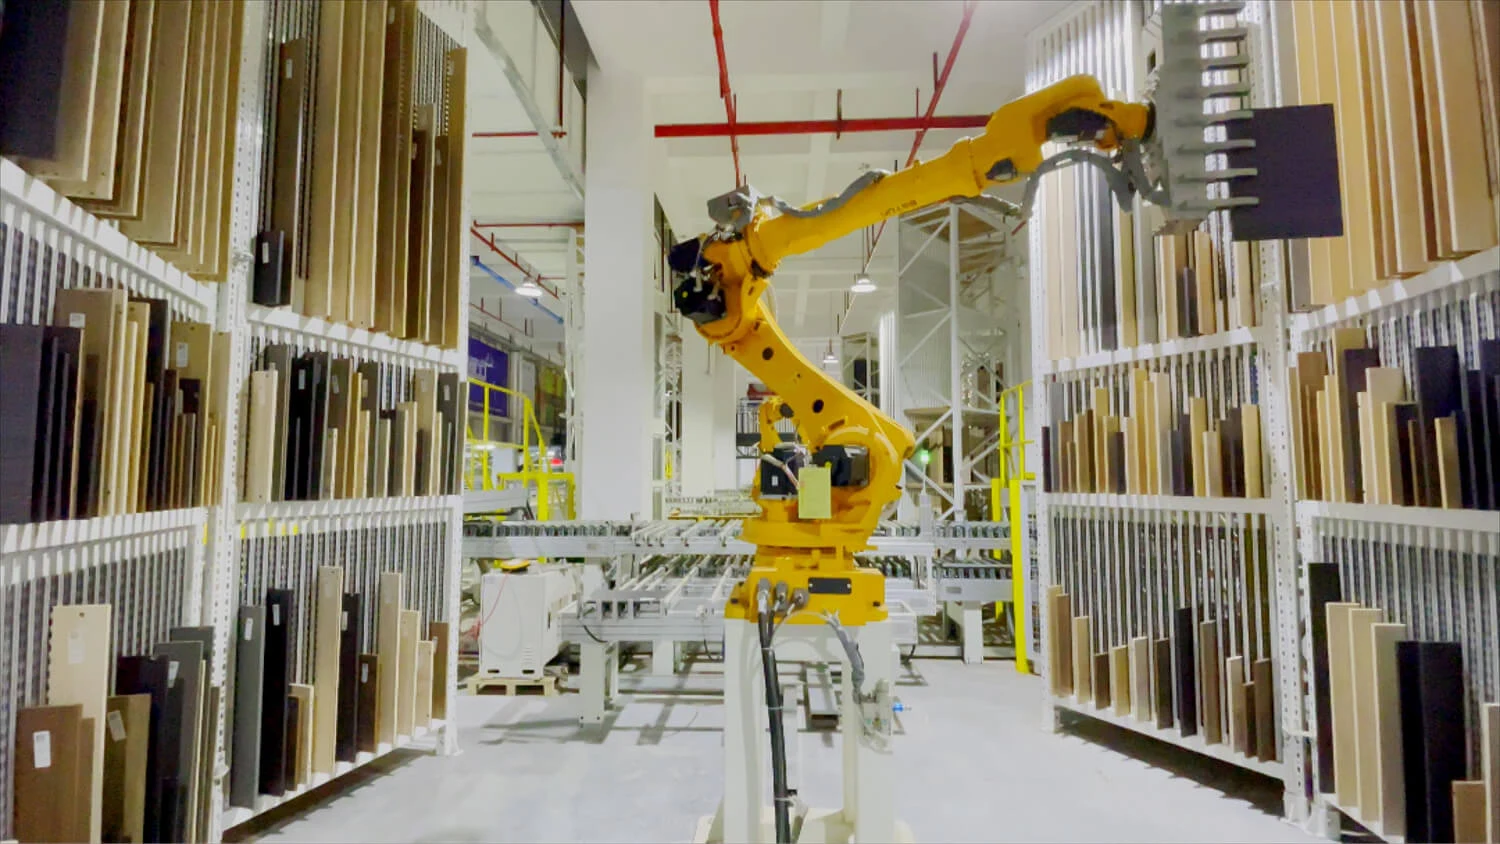
Material handling and part transfer
Move, orient and place parts between workstations. Arm selection starts with actual gripping requirements and interfaces to conveyors, presses or inspection stations.
Information and trials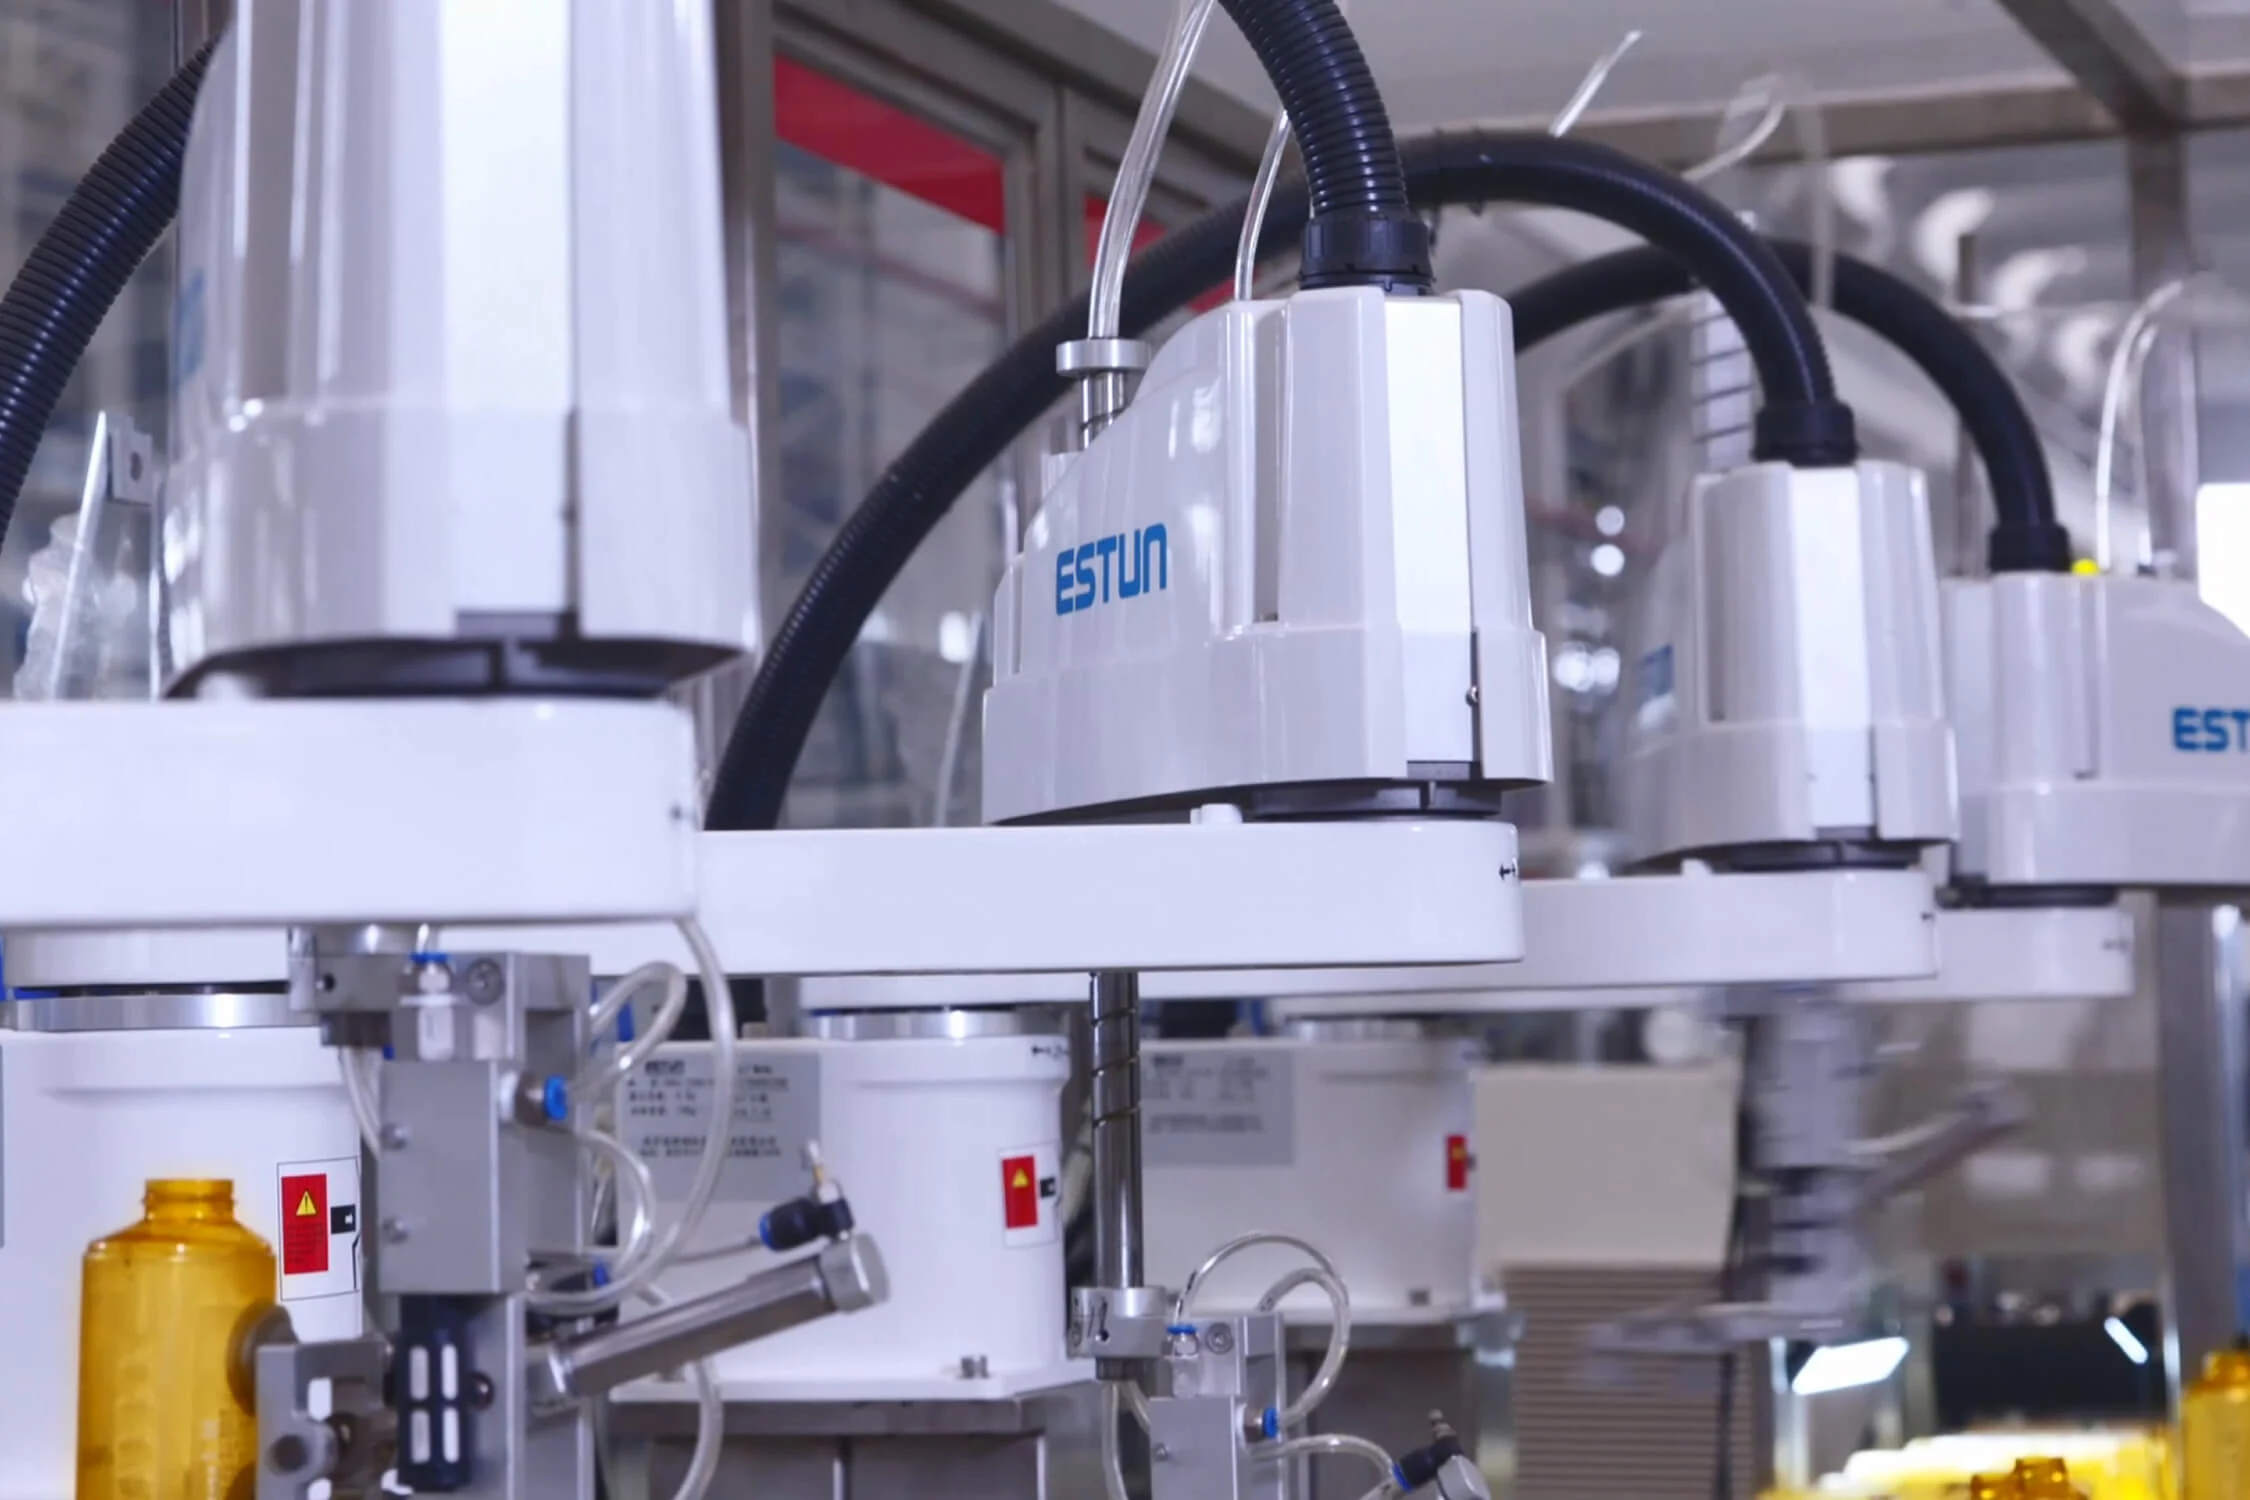
Assembly and screwdriving
Present, insert or fasten components in a controlled sequence. The cell connects handling to inspection equipment and rejected-part management.
Information and trialsDeburring, sanding and polishing
Repeat a tool path over a part or present a part to a fixed tool. Process development covers contact force, consumable wear and the required surface finish.
Information and trials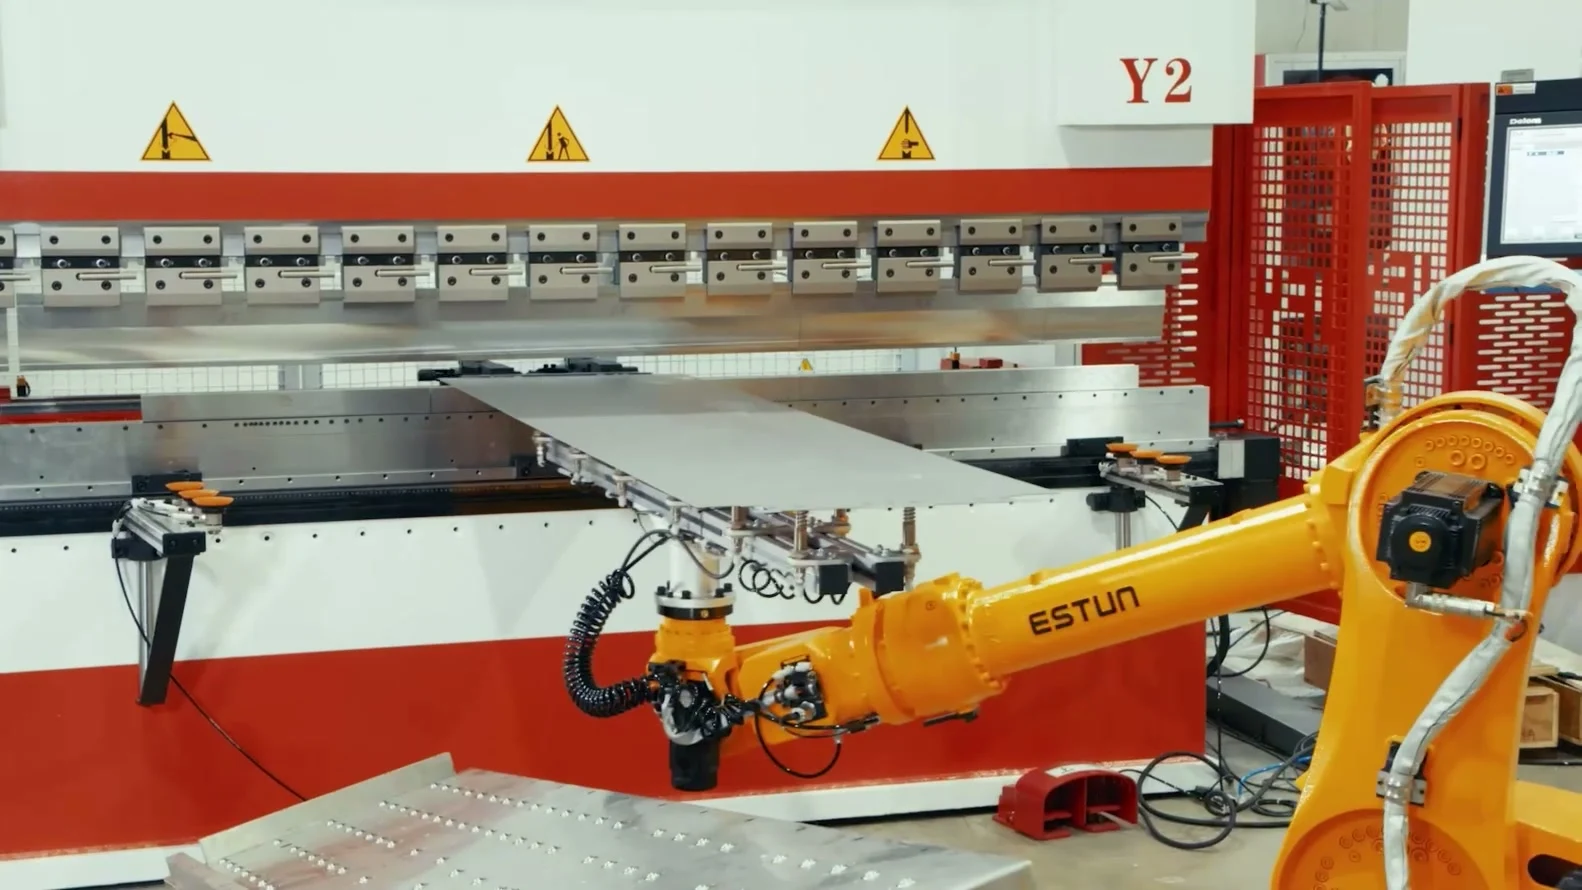
Robotic sheet-metal bending
Load a press brake and reposition sheet metal between bends. The cell must hold the part, follow the bending sequence and manage regripping.
Information and trialsSorting, picking and packing
Pick products, orient them and place them in packaging or the next workstation. Feeding and gripping are designed around actual variations in product flow.
Information and trialsProject questions
Before choosing a robot.
Does the quotation include all equipment?
It lists included equipment and services, exclusions and customer-supplied items. Boundaries between work packages must be explicit.
Who validates the cell before production?
Responsibilities and required evidence are identified in the project. Technical acceptance, safety validation and operational approval each have their own criteria.