
Vanguard Robotics / ESTUN integration partner
Sorting, picking and packing
Pick products, orient them and place them in packaging or the next workstation. Feeding and gripping are designed around actual variations in product flow.
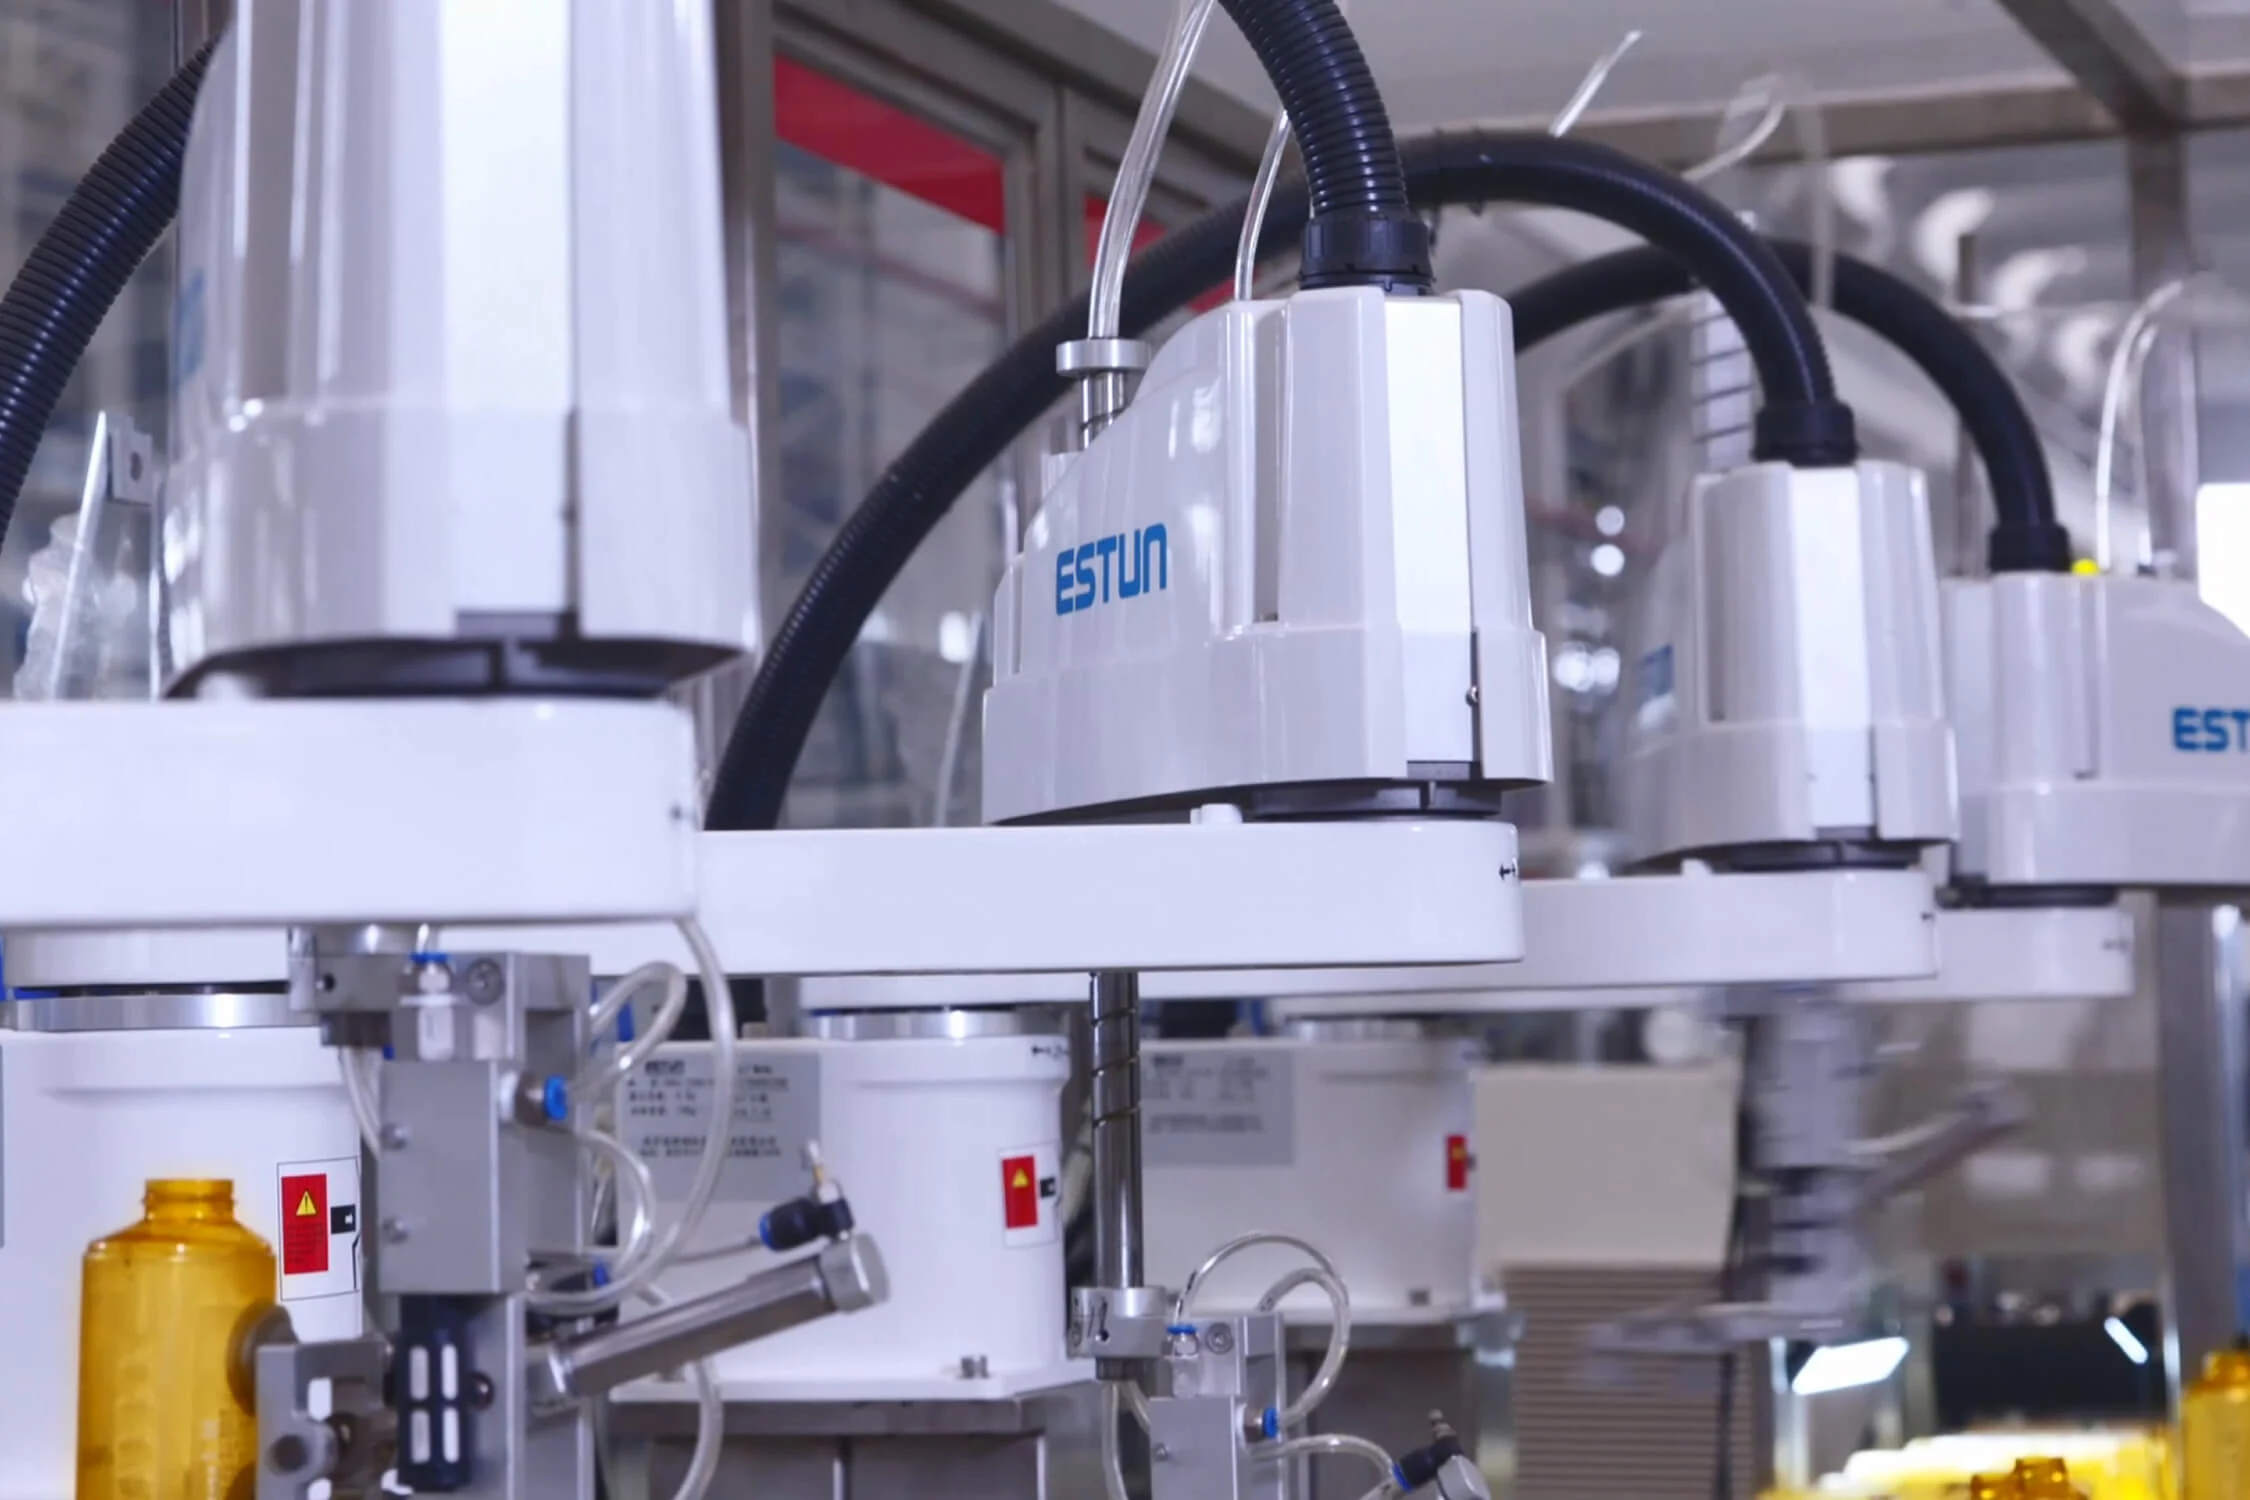
The process
Define every step of the operation.
Record product formats, fragility and presentation.
Study gripping, conveyor synchronisation and any vision inspections.
Plan packaging supply, missing products and rejects.
Measure throughput using a representative format mix.
Selection to confirm
Families to consider.
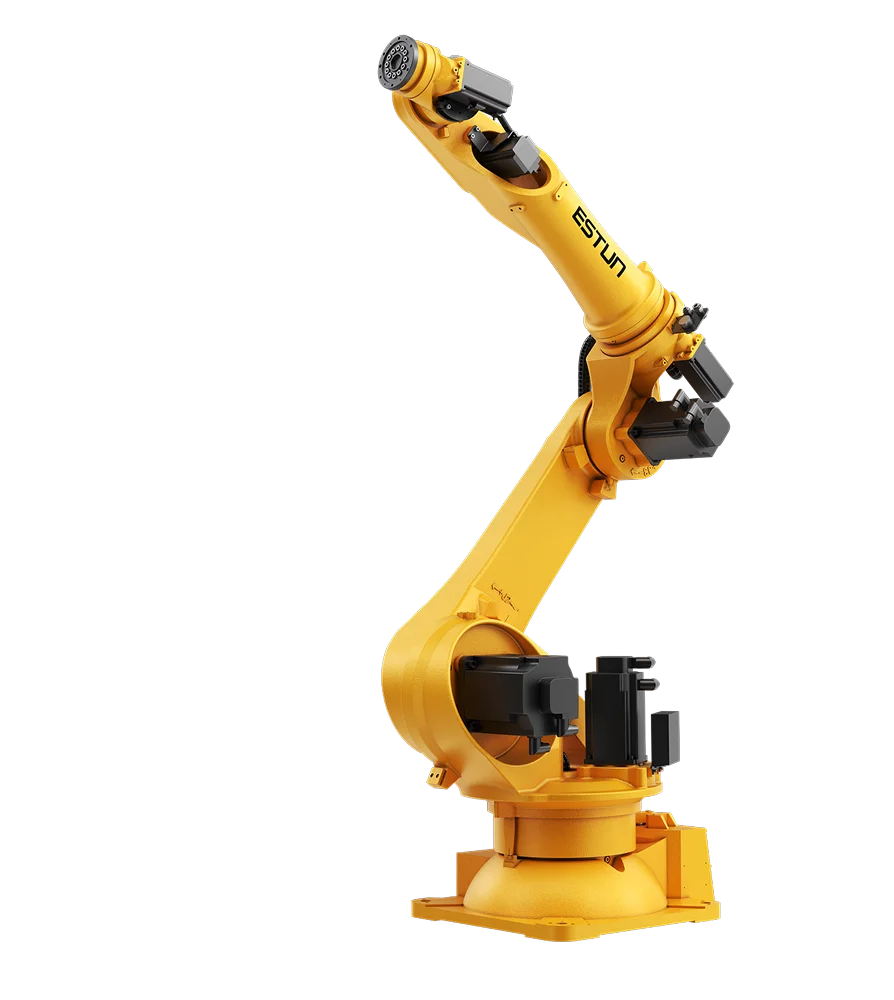
6-axis articulated robots
Articulated arms for machine tending, part orientation and process paths. The models shown cover small and medium payloads.
18 documented models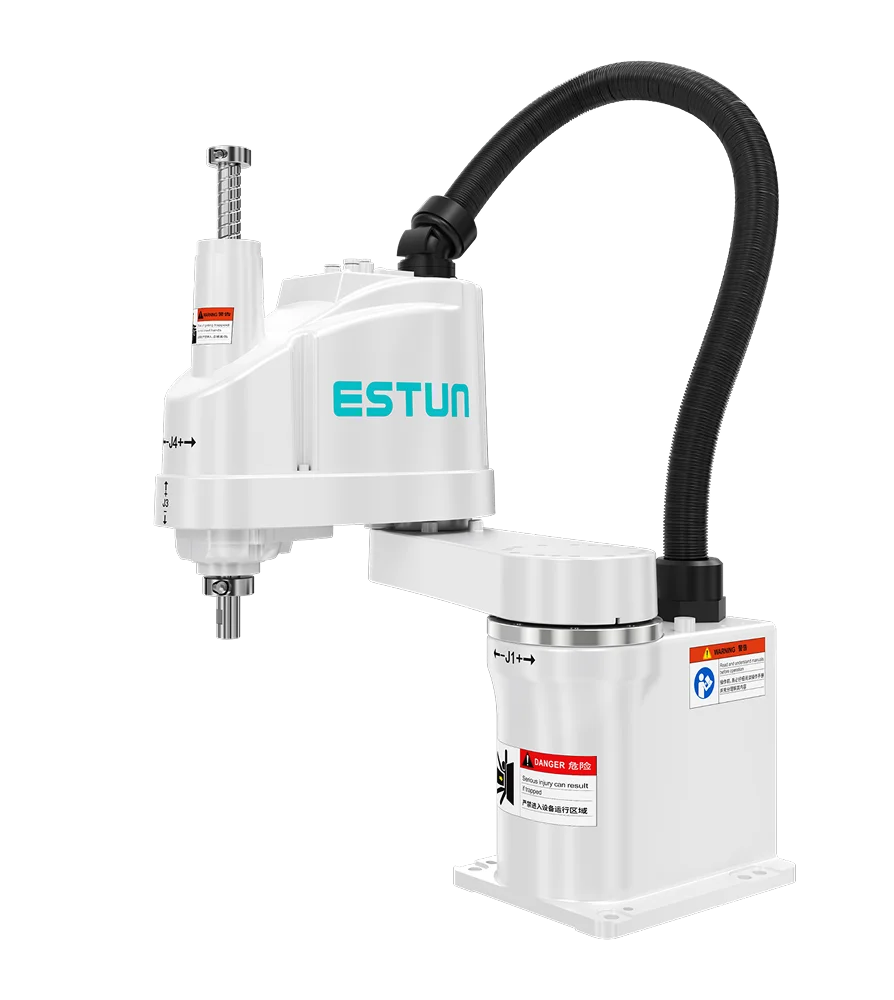
4-axis SCARA robots
4-axis robots for picking, orienting and placing parts within a planar workspace. Several payloads and vertical strokes are documented.
24 documented models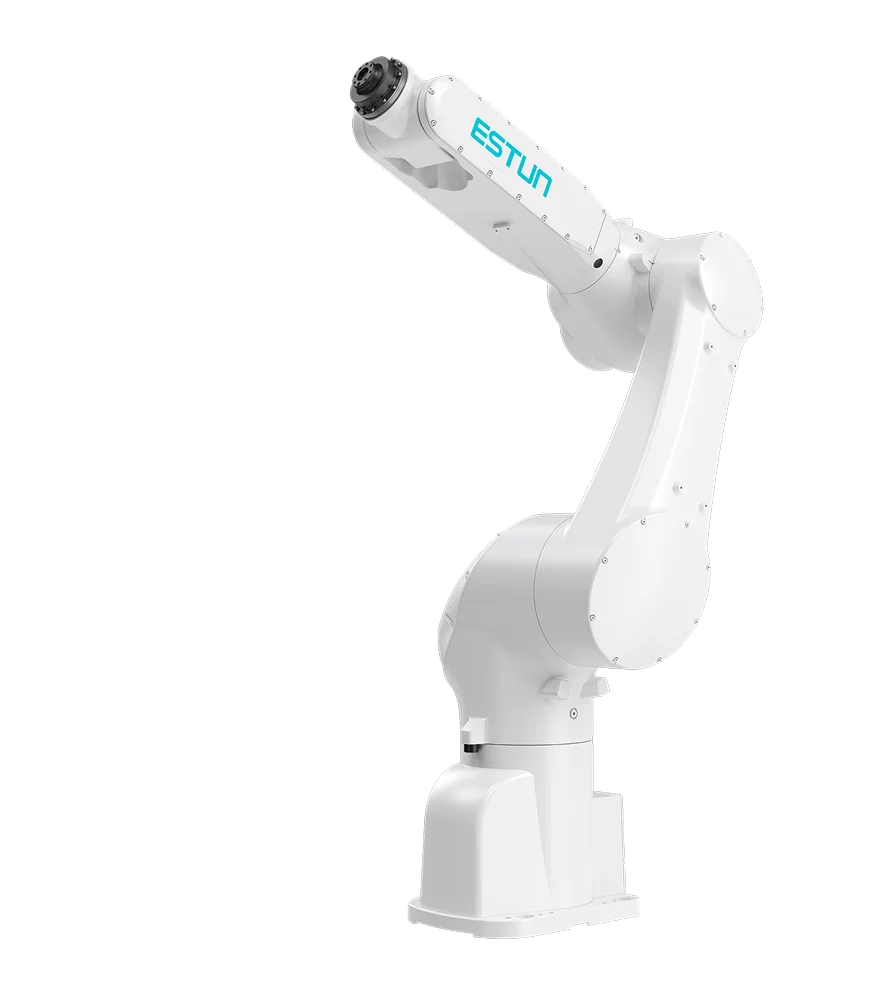
Compact MINI robots
Compact arms for machine tending, assembly and part handling where space is limited. The European range includes 6-axis arms; the global catalogue also documents 3-axis and 4-axis variants.
10 documented models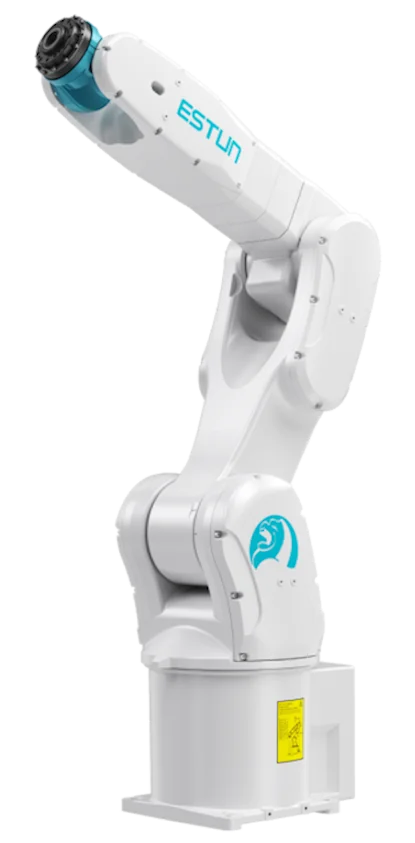
Cleanroom robot variants
SCARA and MINI variants identified for cleanroom use in ESTUN’s European catalogue. The model documentation must establish the cleanliness and operating conditions required by the project.
6 documented modelsValidation depends on the parts, tooling, cycle trials and cell risk assessment.
Project questions
Before choosing a robot.
Is vision required for sorting?
Vision can identify products or locate them. Mechanical guidance or sensors may be enough when presentation is repeatable. The choice depends on the defect or variation to detect.
Can formats change without reprogramming the whole cell?
Recipes can group the positions, dimensions and sequences for each format. Covered formats, tool changes and operator actions are defined during design.