
Vanguard Robotics / ESTUN integration partner
Industrial robotics applications
Palletising, machine tending, welding and assembly. The information and trials needed to specify your robotic cell.
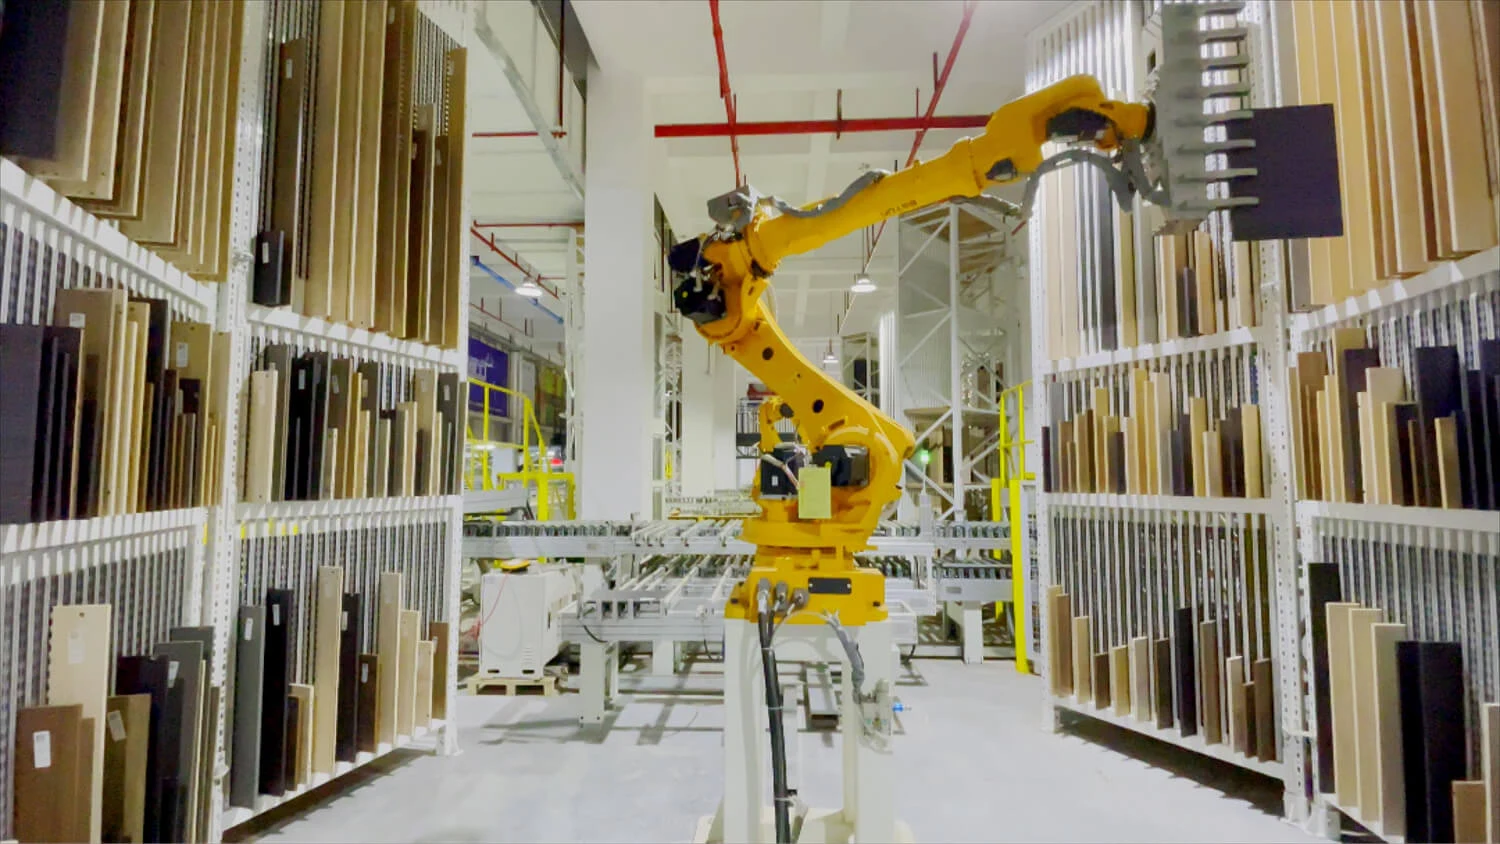
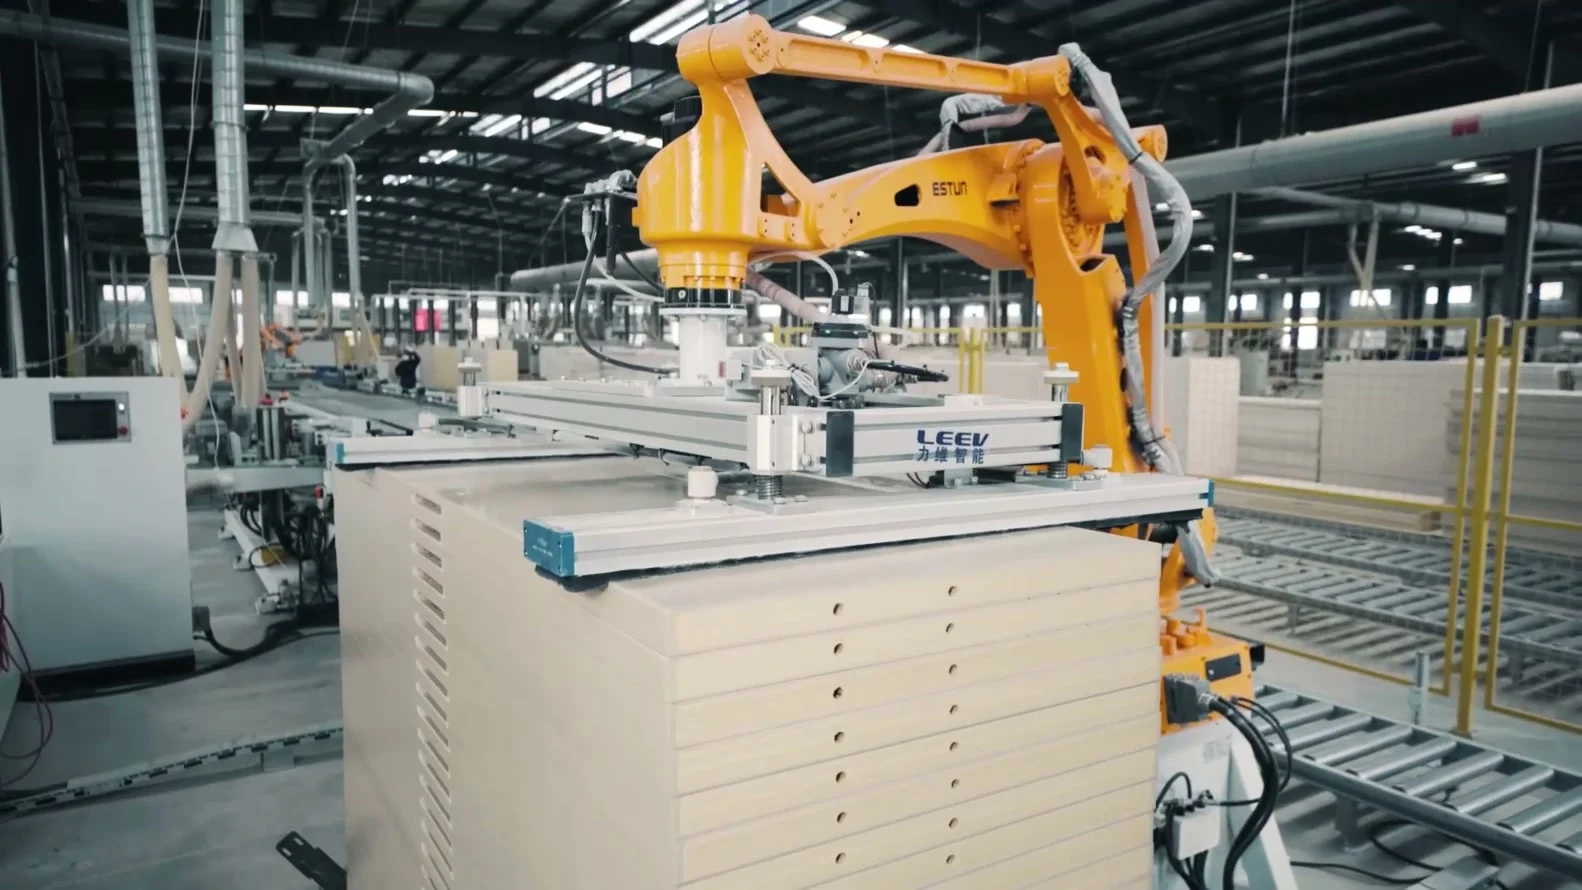
Palletising and depalletising
Stack cases, bags or totes at the end of the line. The project connects the gripper, conveyors and pallet patterns to your production requirements.
See what needs checking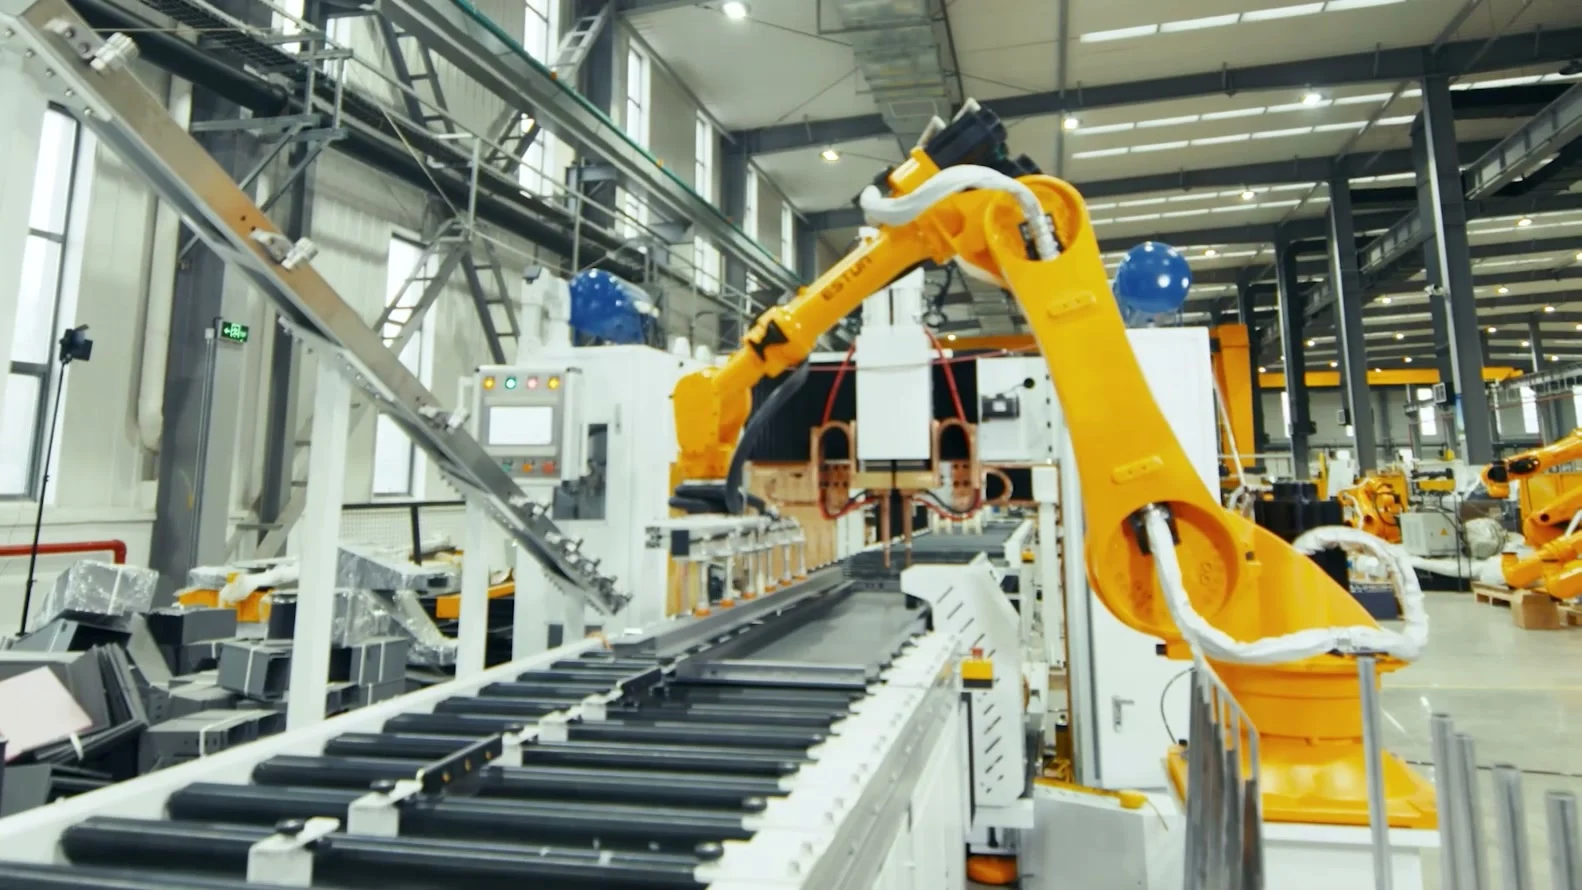
Machine tending
Load and unload a machining centre, lathe or another production machine. The cell coordinates part gripping, doors, clamping and machine states.
See what needs checking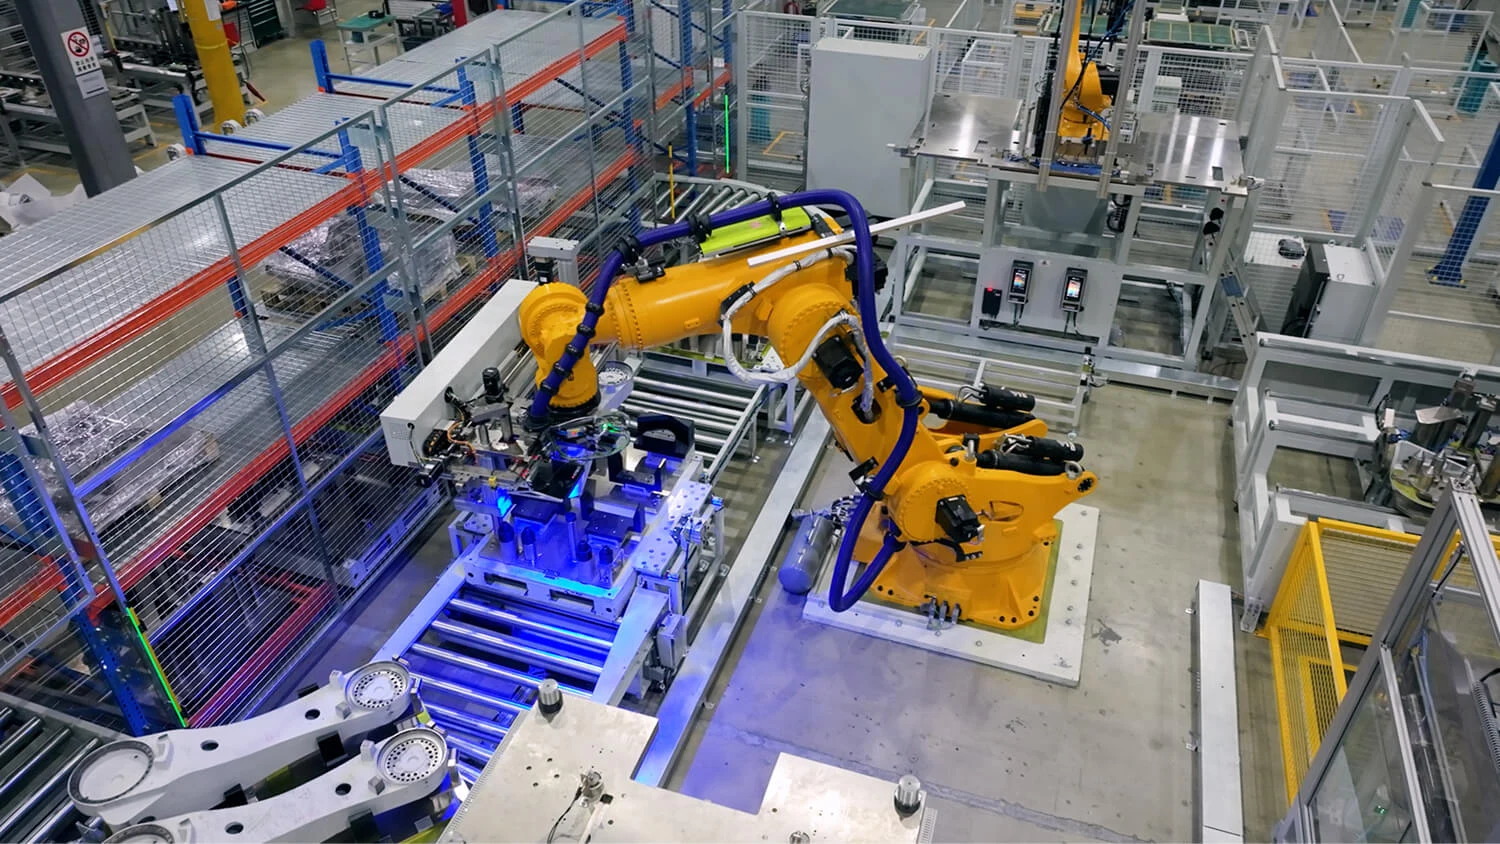
Robotic welding
Repeat weld seams on fixtured parts. Integration combines the robot, torch, power source and positioner with the selected welding process.
See what needs checkingMaterial handling and part transfer
Move, orient and place parts between workstations. Arm selection starts with actual gripping requirements and interfaces to conveyors, presses or inspection stations.
See what needs checking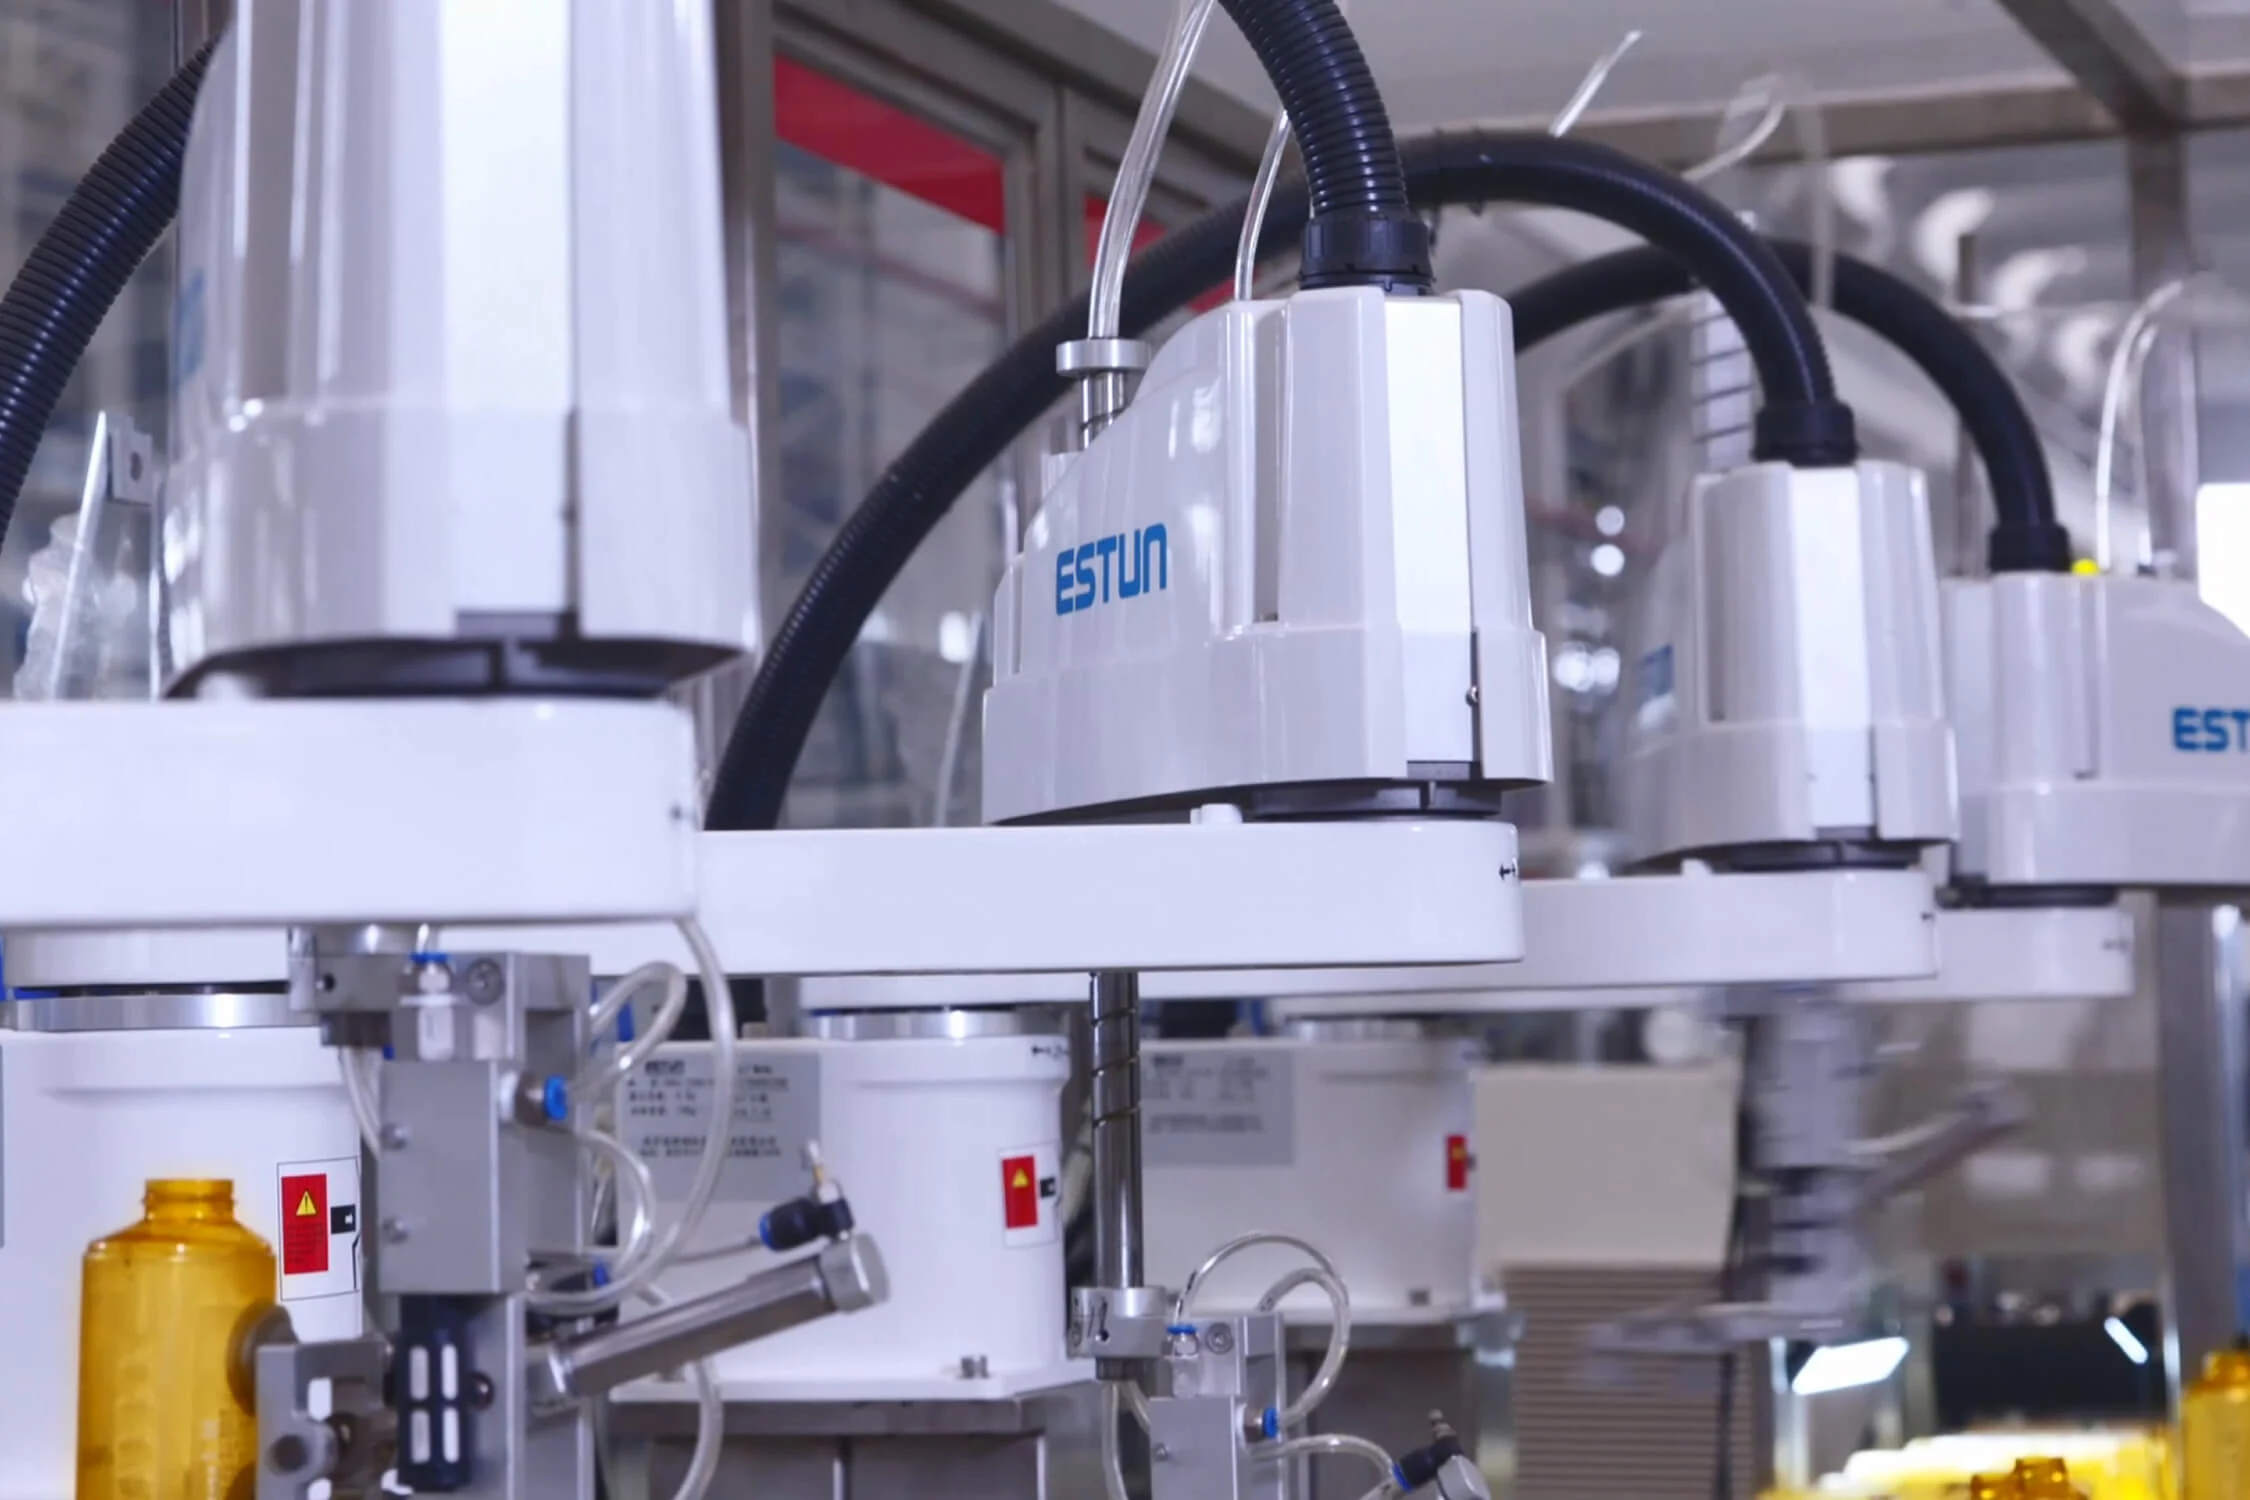
Assembly and screwdriving
Present, insert or fasten components in a controlled sequence. The cell connects handling to inspection equipment and rejected-part management.
See what needs checkingDeburring, sanding and polishing
Repeat a tool path over a part or present a part to a fixed tool. Process development covers contact force, consumable wear and the required surface finish.
See what needs checking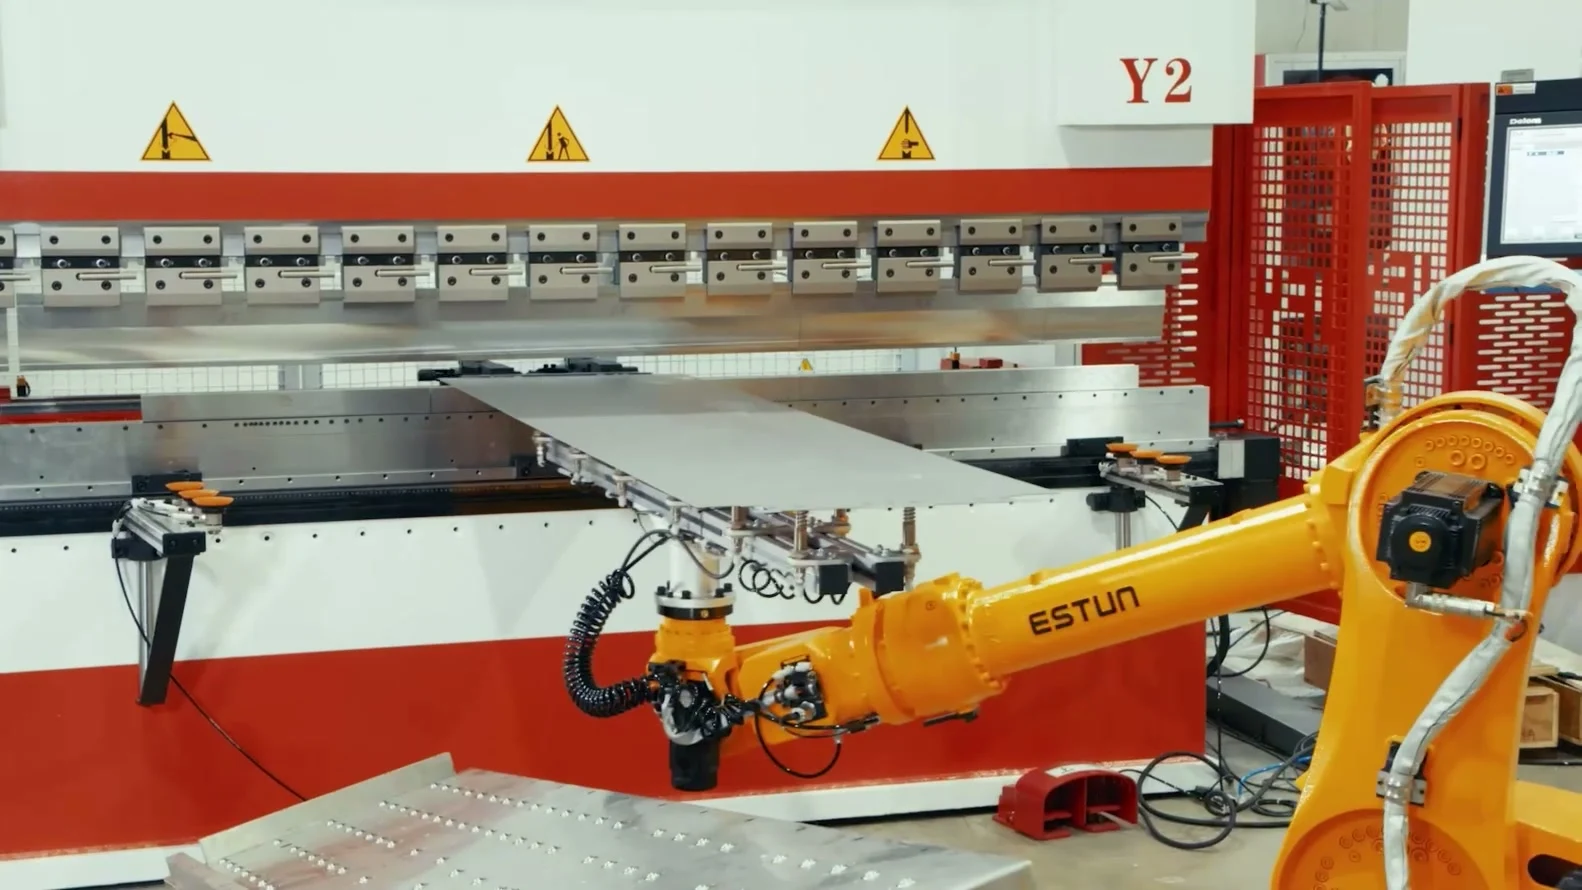
Robotic sheet-metal bending
Load a press brake and reposition sheet metal between bends. The cell must hold the part, follow the bending sequence and manage regripping.
See what needs checkingSorting, picking and packing
Pick products, orient them and place them in packaging or the next workstation. Feeding and gripping are designed around actual variations in product flow.
See what needs checkingThese pages describe potential applications. They are not customer project references.