
Vanguard Robotics / ESTUN integration partner
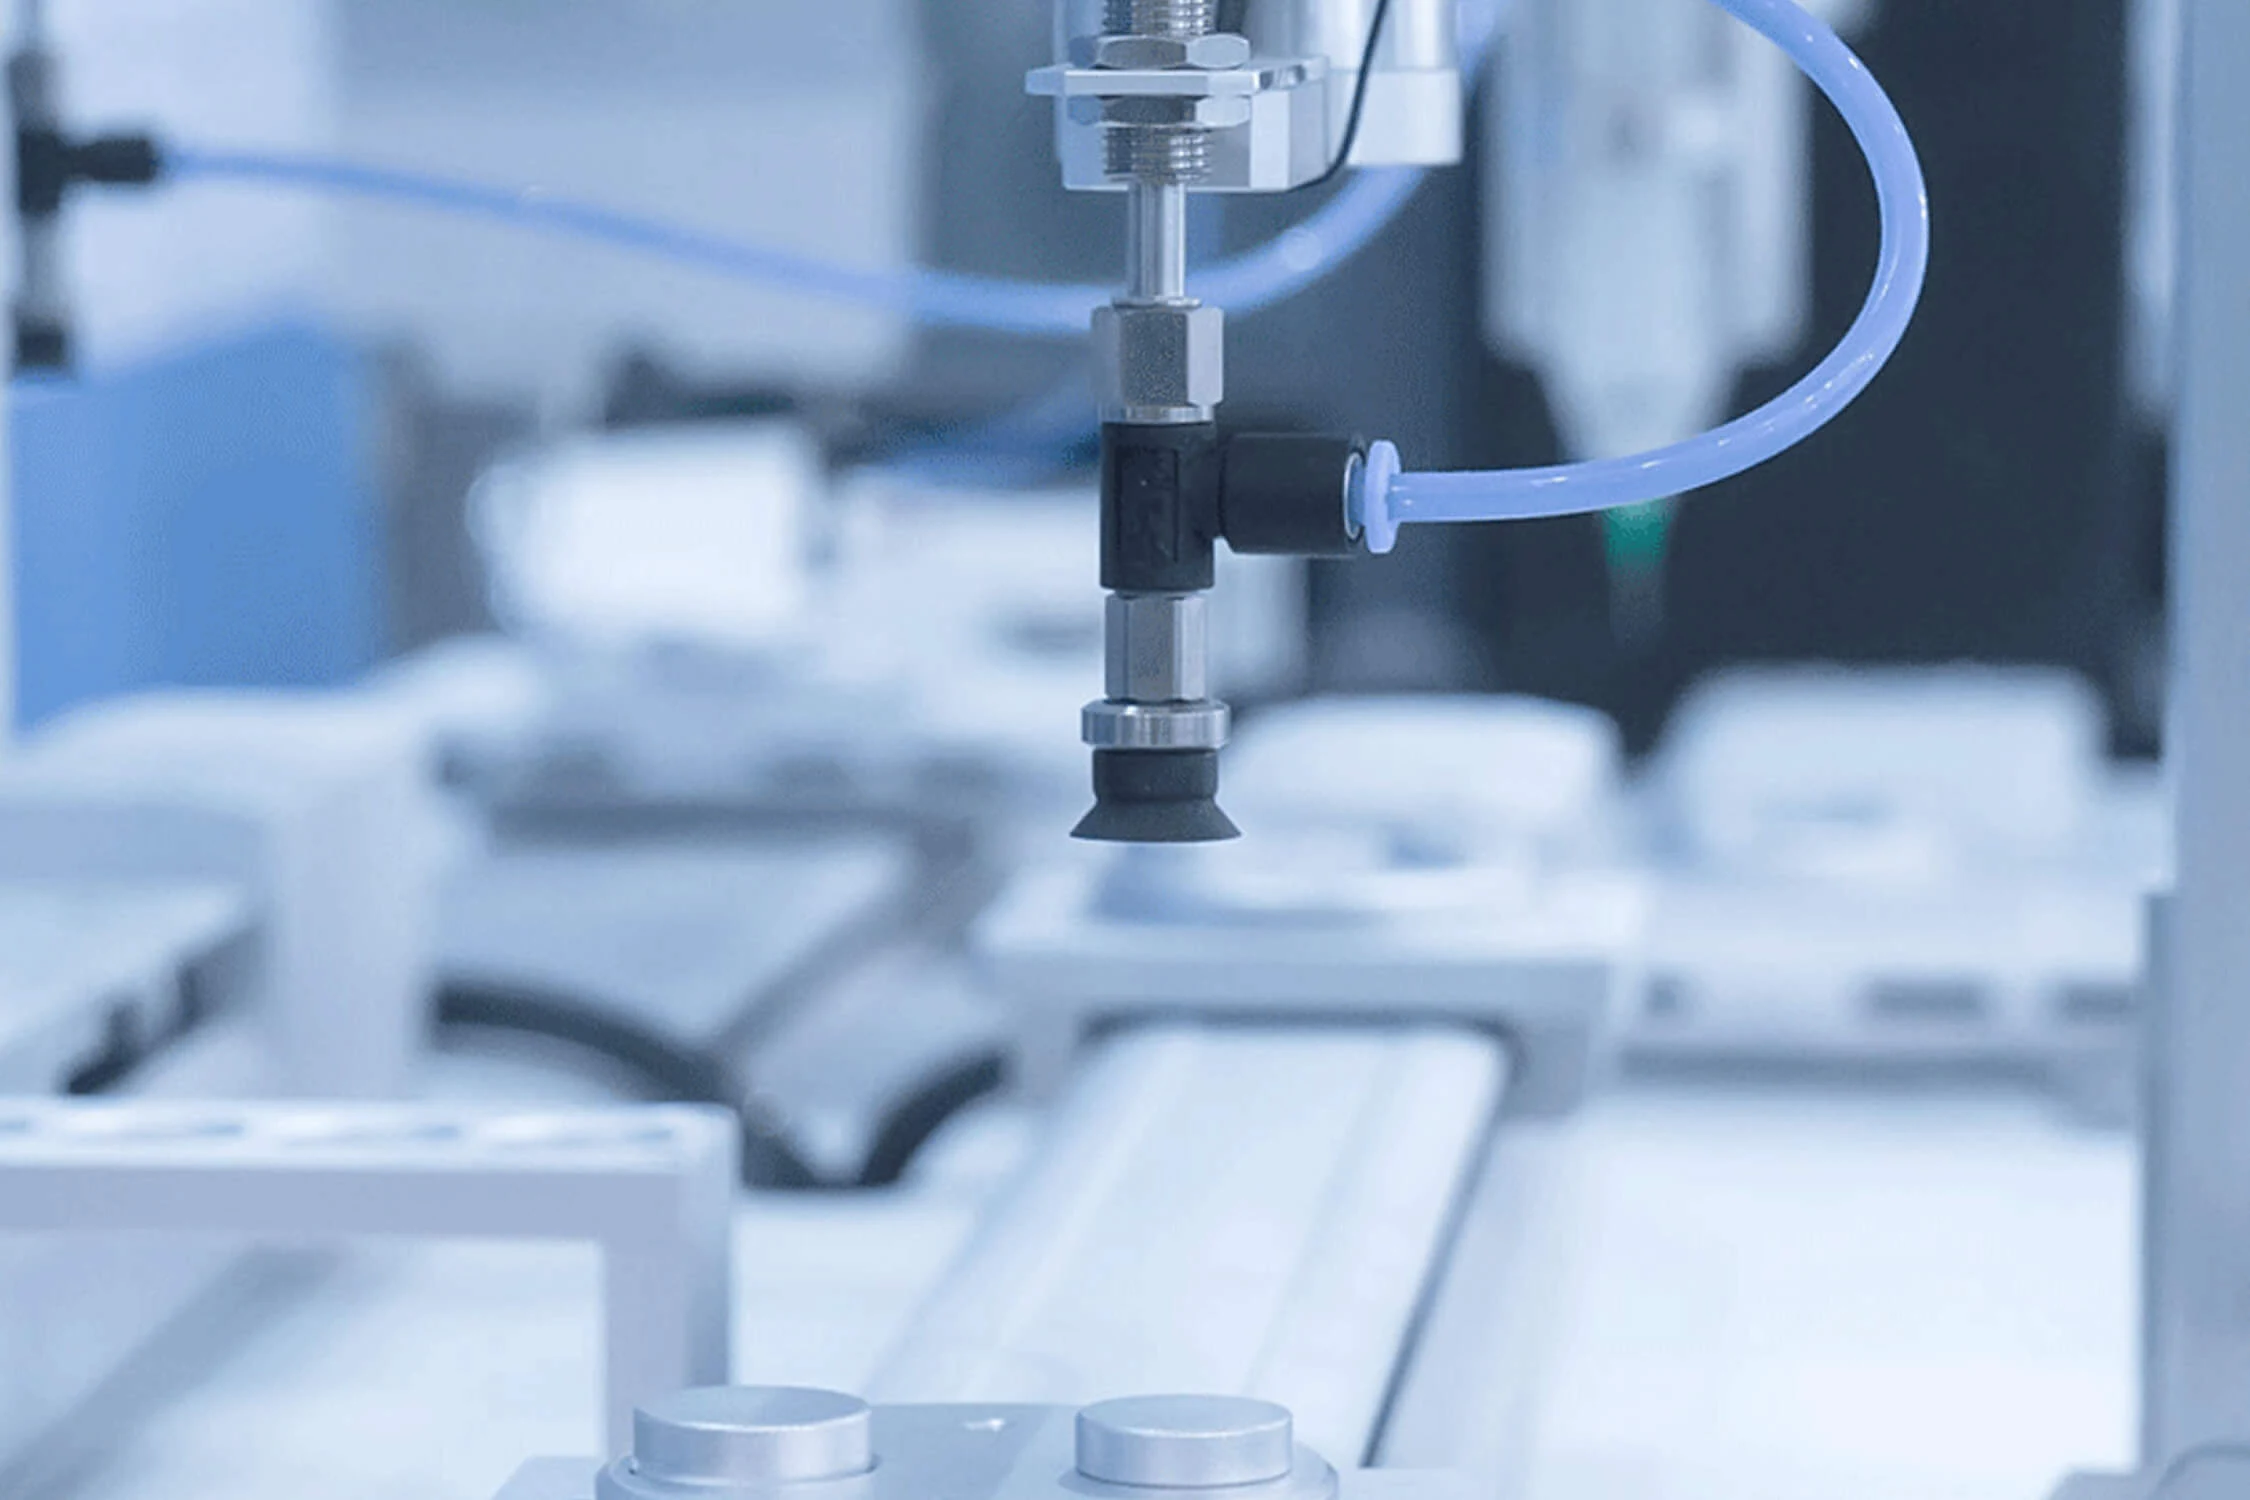
Robot vision and gripping
Validate gripping and part detection under actual workstation conditions.
Your starting point
Robot vision and gripping
For a workstation where part position, surface or variety makes picking uncertain, or inspection is required during handling.
Scope to agree
Study gripping surfaces, part variation and loss-of-power states.
Select the gripping principle and sensors needed for verification.
Evaluate vision on representative parts, lighting and positions.
Connect detection results to motions, rejection and fault handling.
Prepare the work
Information to share with us.
- Samples covering variation in material, colour, surface finish and position.
- Throughput, working distance, available space and workstation lighting.
- Target defects and acceptance or rejection criteria.
Acceptance and limitations
Trials use a sample set agreed with the customer. Successful grips, failures, false rejects and indeterminate cases are recorded separately. Untested conditions remain identified.
The quotation distinguishes equipment supply, integration, trials and services after commissioning. Open points remain identified.
Applications
Connect the service to your process.
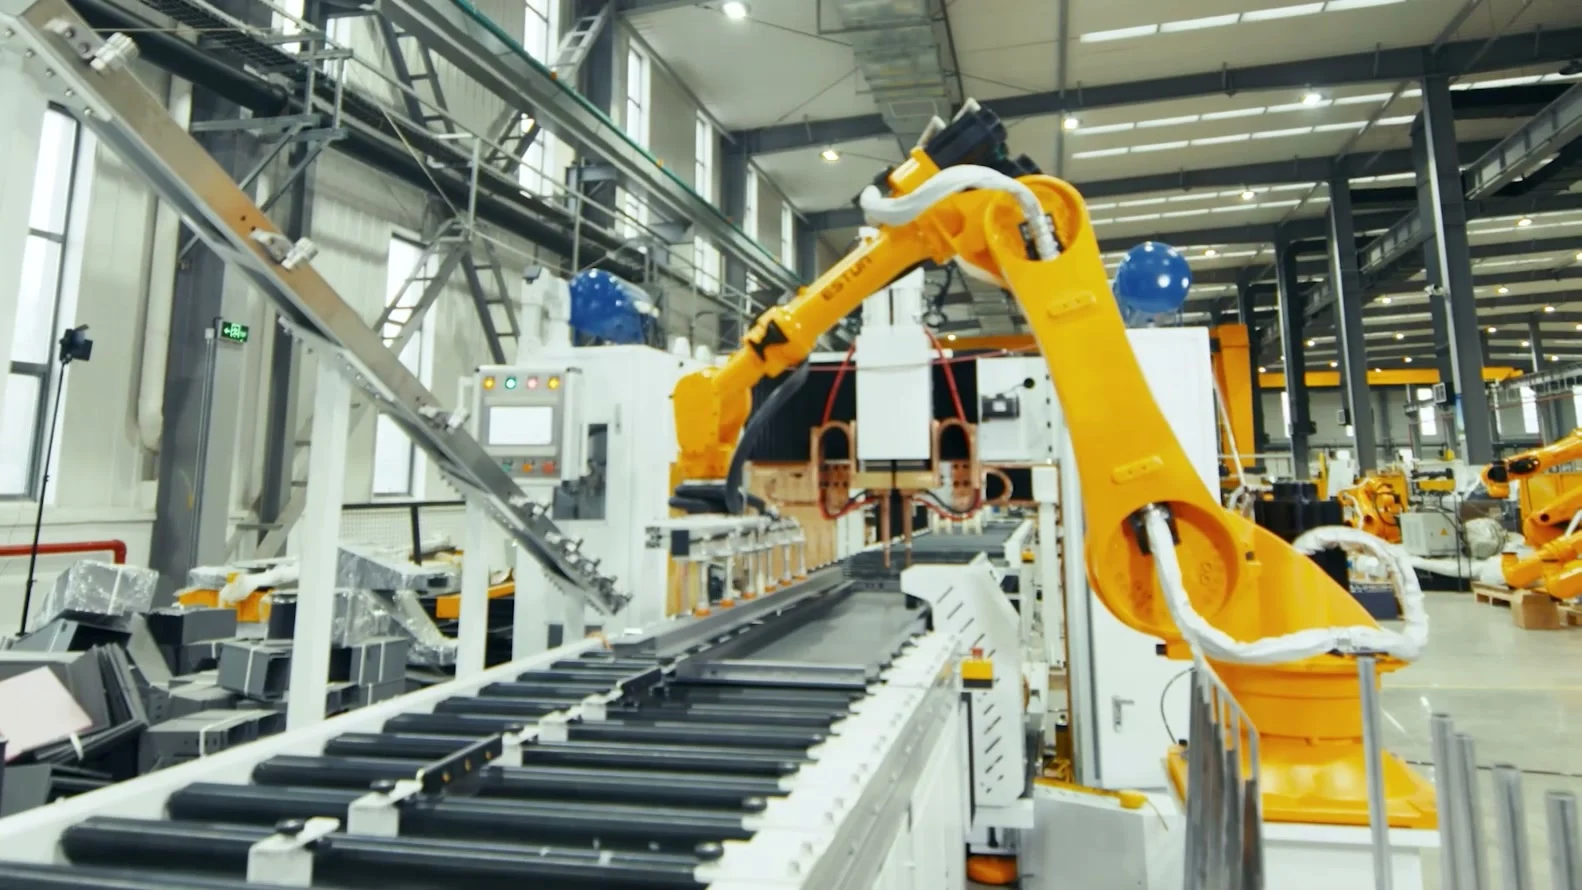
Machine tending
Load and unload a machining centre, lathe or another production machine. The cell coordinates part gripping, doors, clamping and machine states.
Information and trials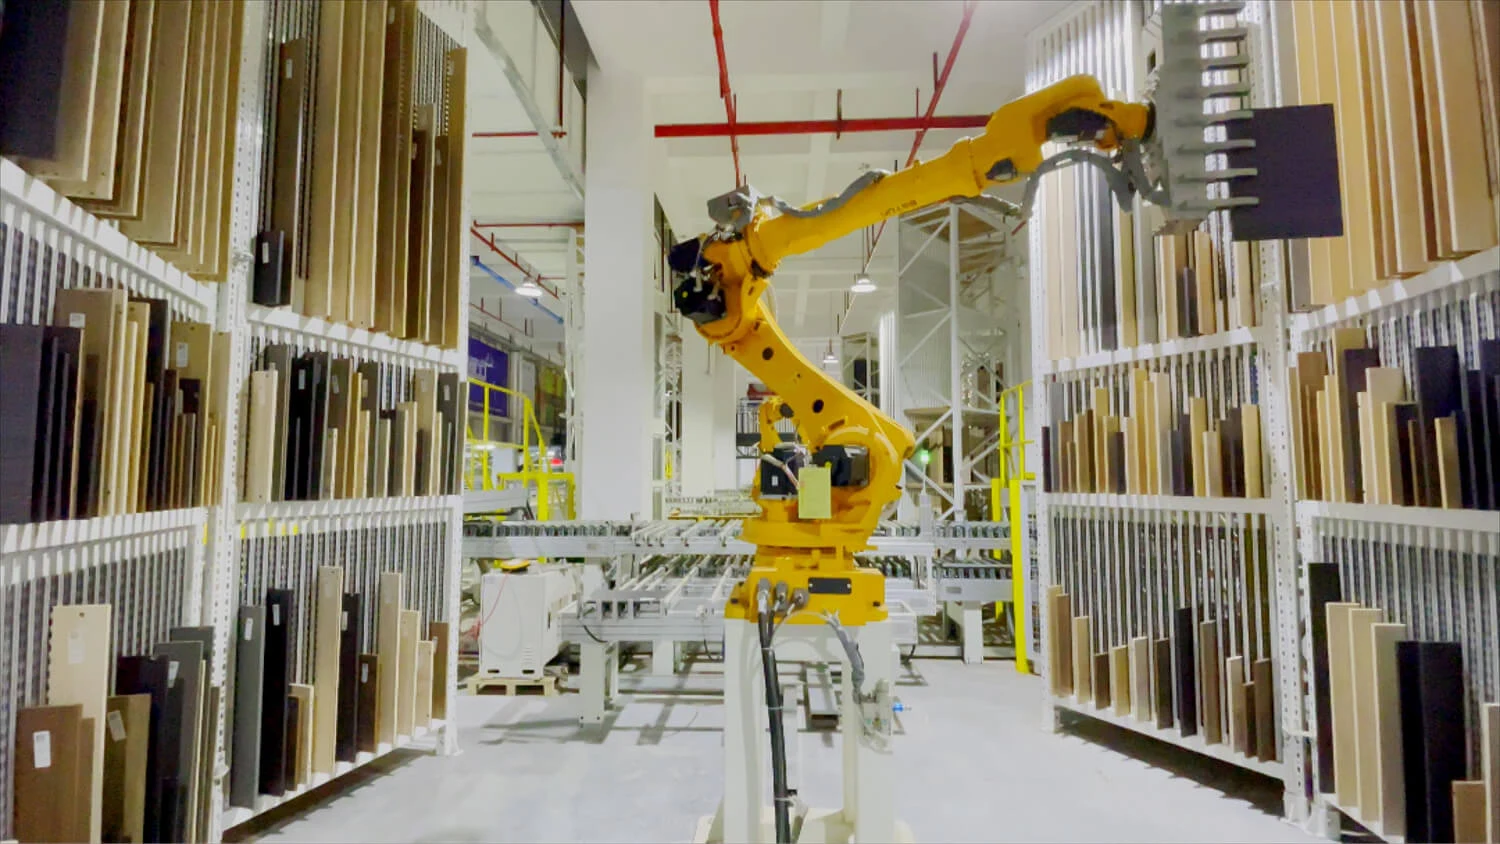
Material handling and part transfer
Move, orient and place parts between workstations. Arm selection starts with actual gripping requirements and interfaces to conveyors, presses or inspection stations.
Information and trials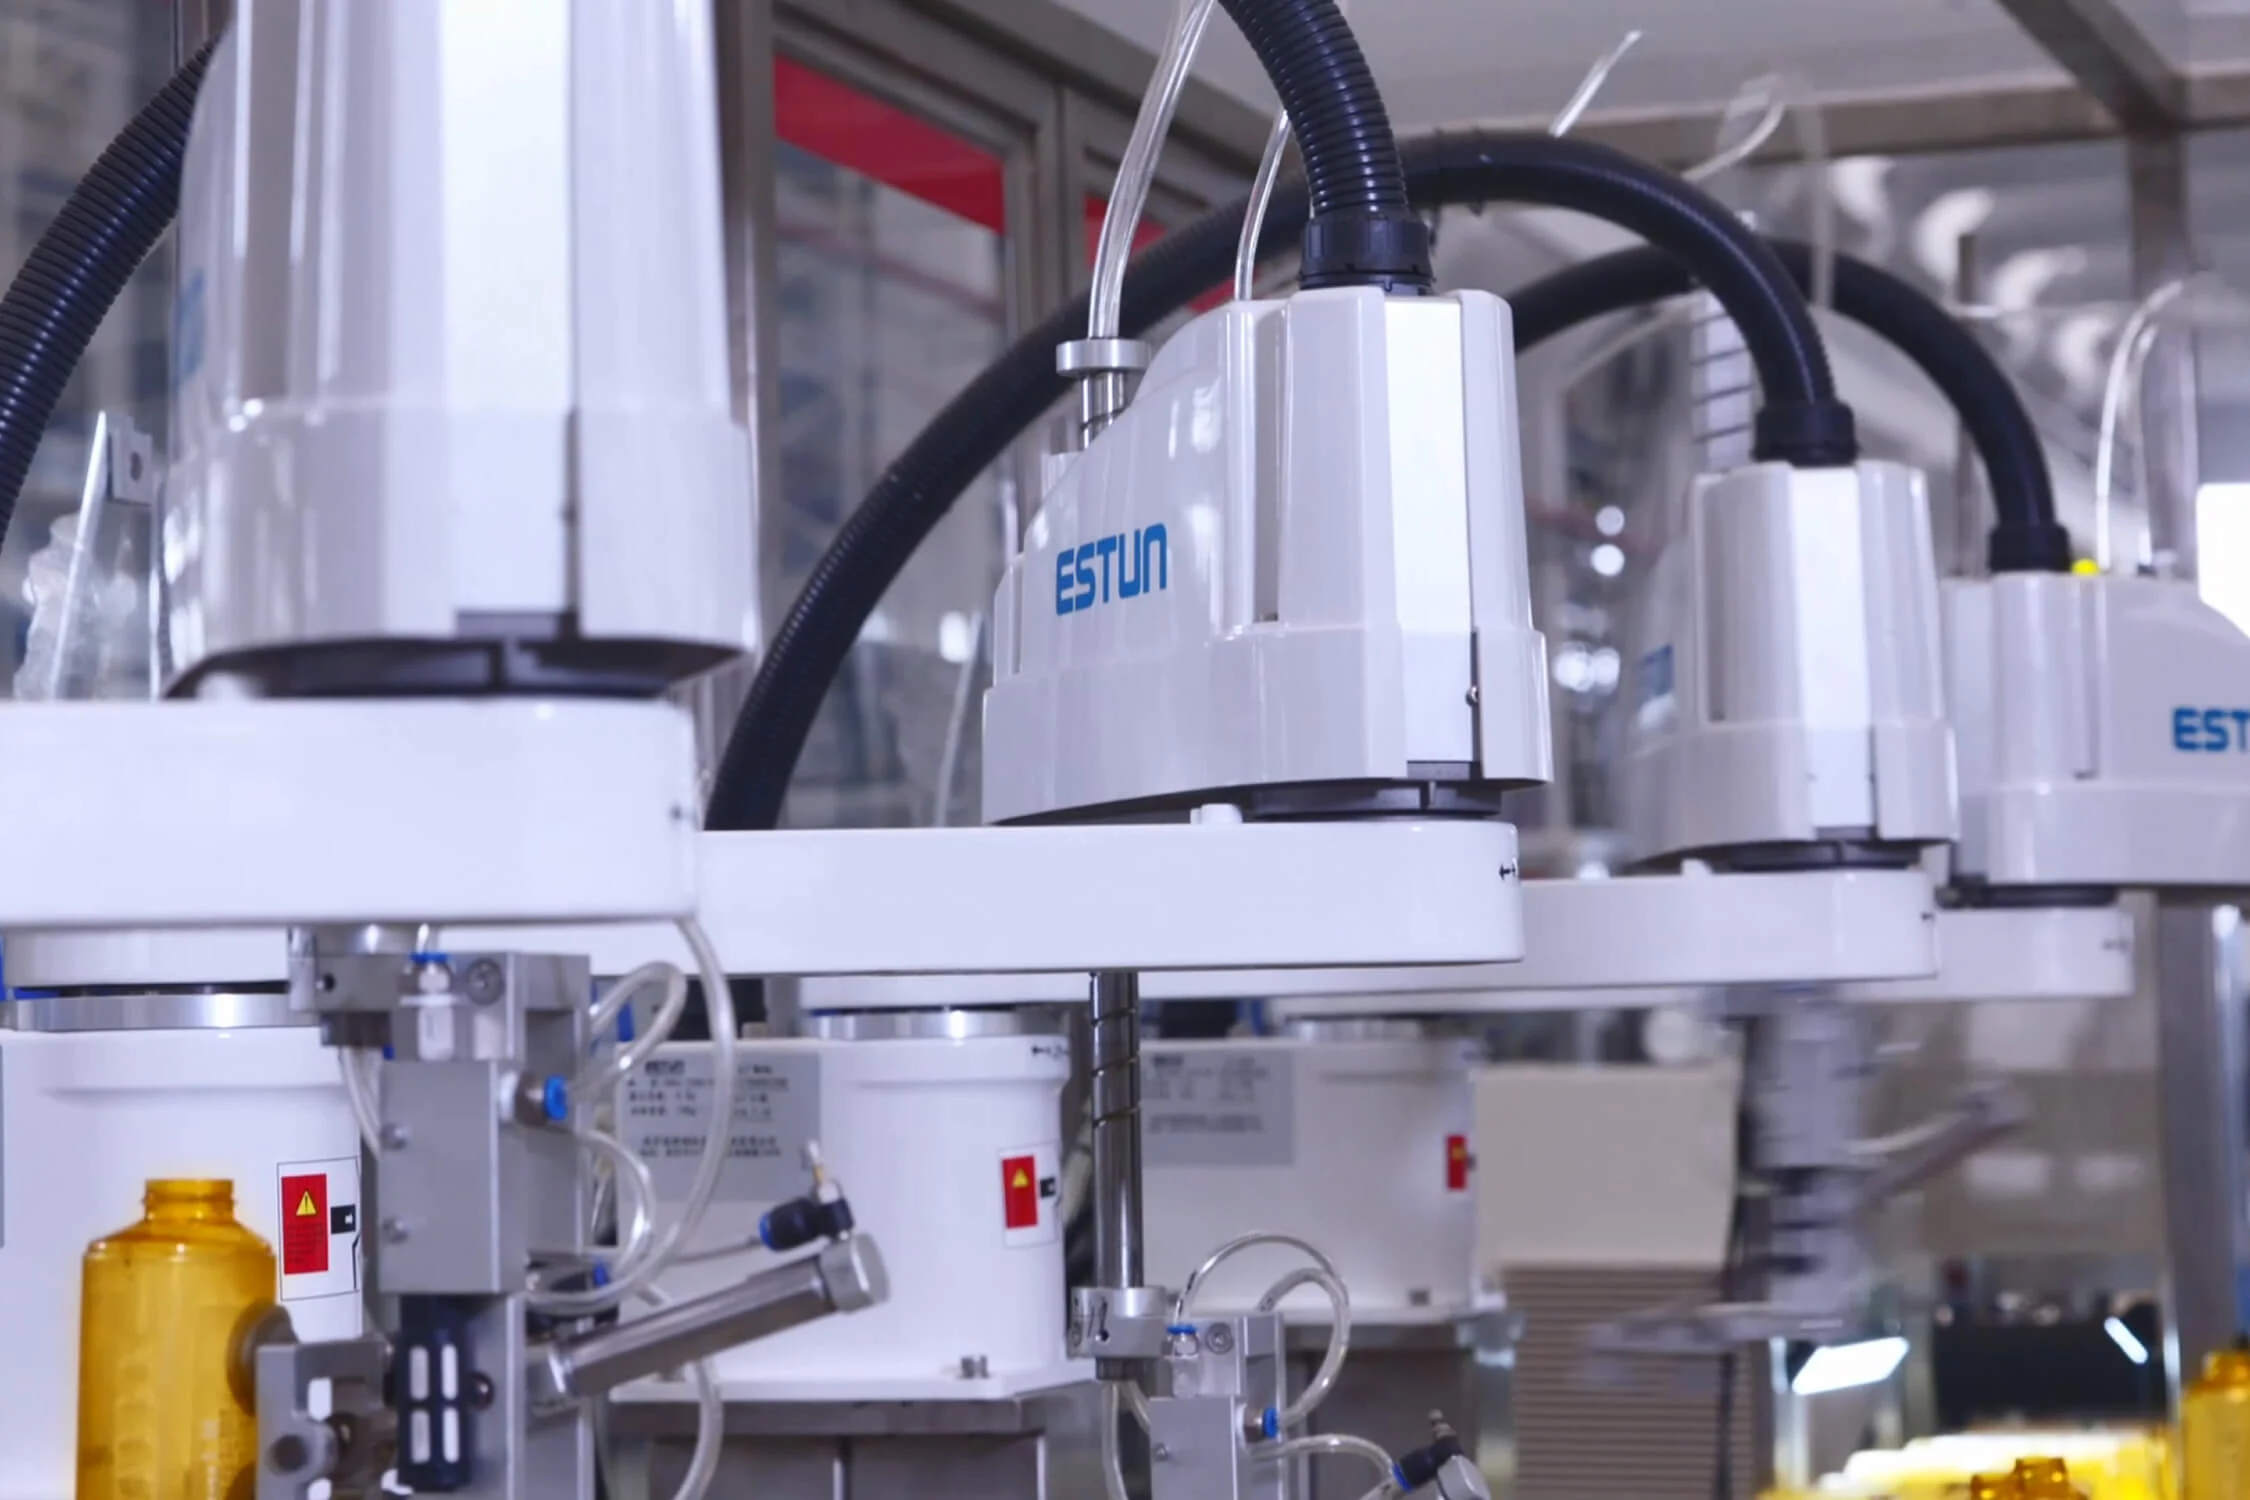
Assembly and screwdriving
Present, insert or fasten components in a controlled sequence. The cell connects handling to inspection equipment and rejected-part management.
Information and trialsSorting, picking and packing
Pick products, orient them and place them in packaging or the next workstation. Feeding and gripping are designed around actual variations in product flow.
Information and trialsTechnical selection
Families to consider.
Project questions
Before choosing a robot.
Does every project need a camera?
Repeatable mechanical presentation may be sufficient. Vision addresses a position variation, identification or inspection requirement that can be defined and tested.
How is a successful grip verified?
Depending on gripping, verification may use pressure, position, force or presence detection. Indeterminate states need a defined response.