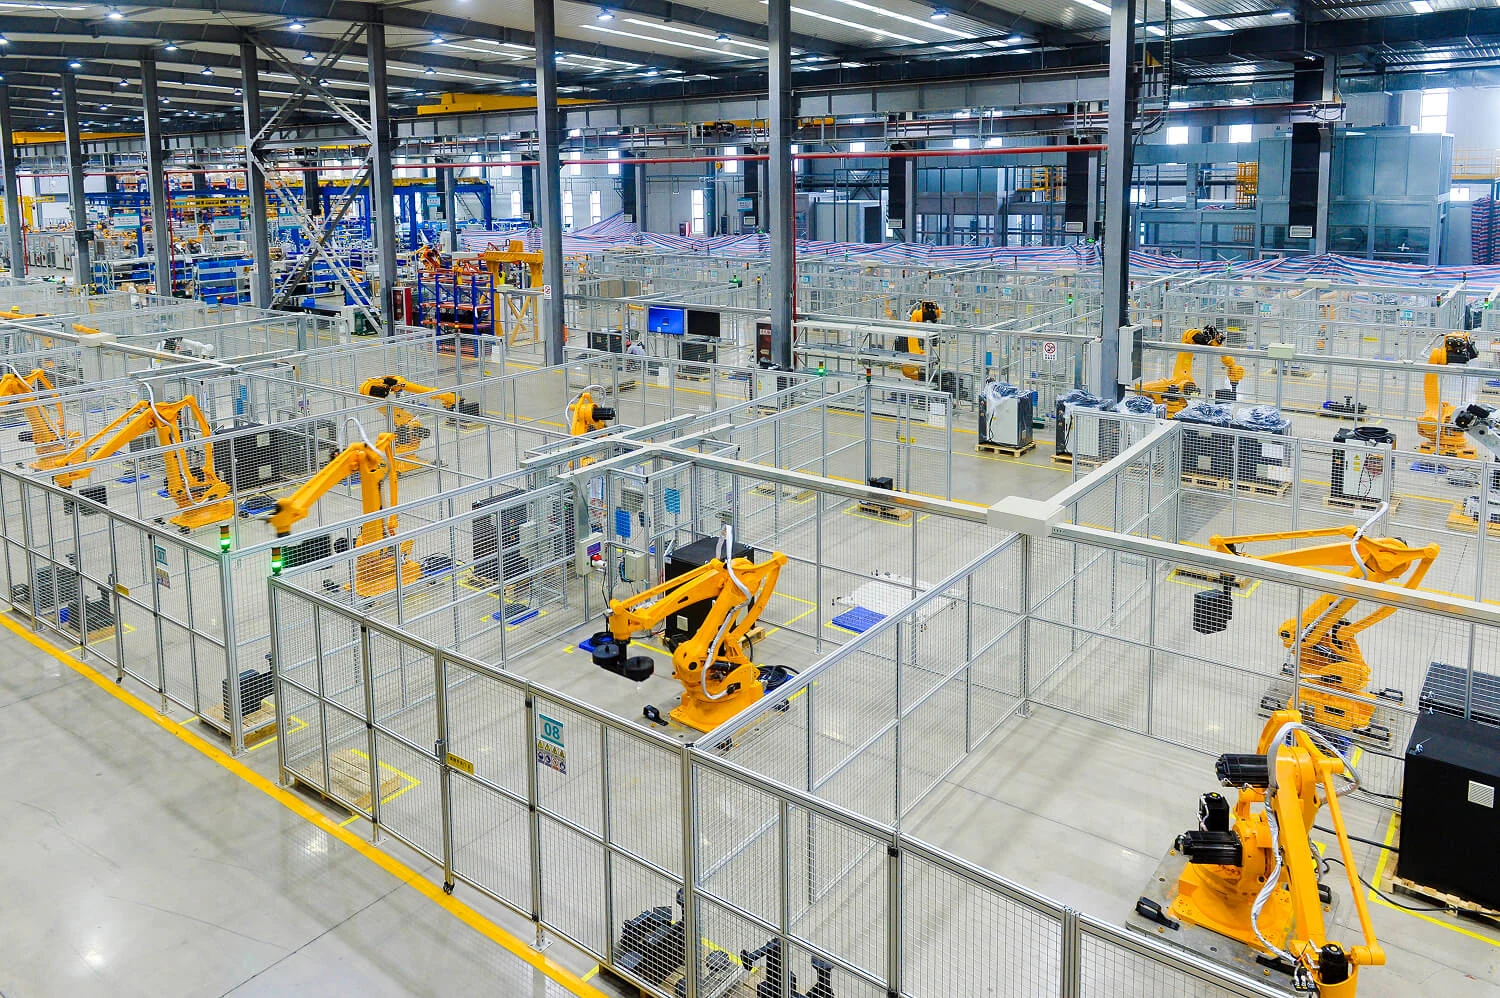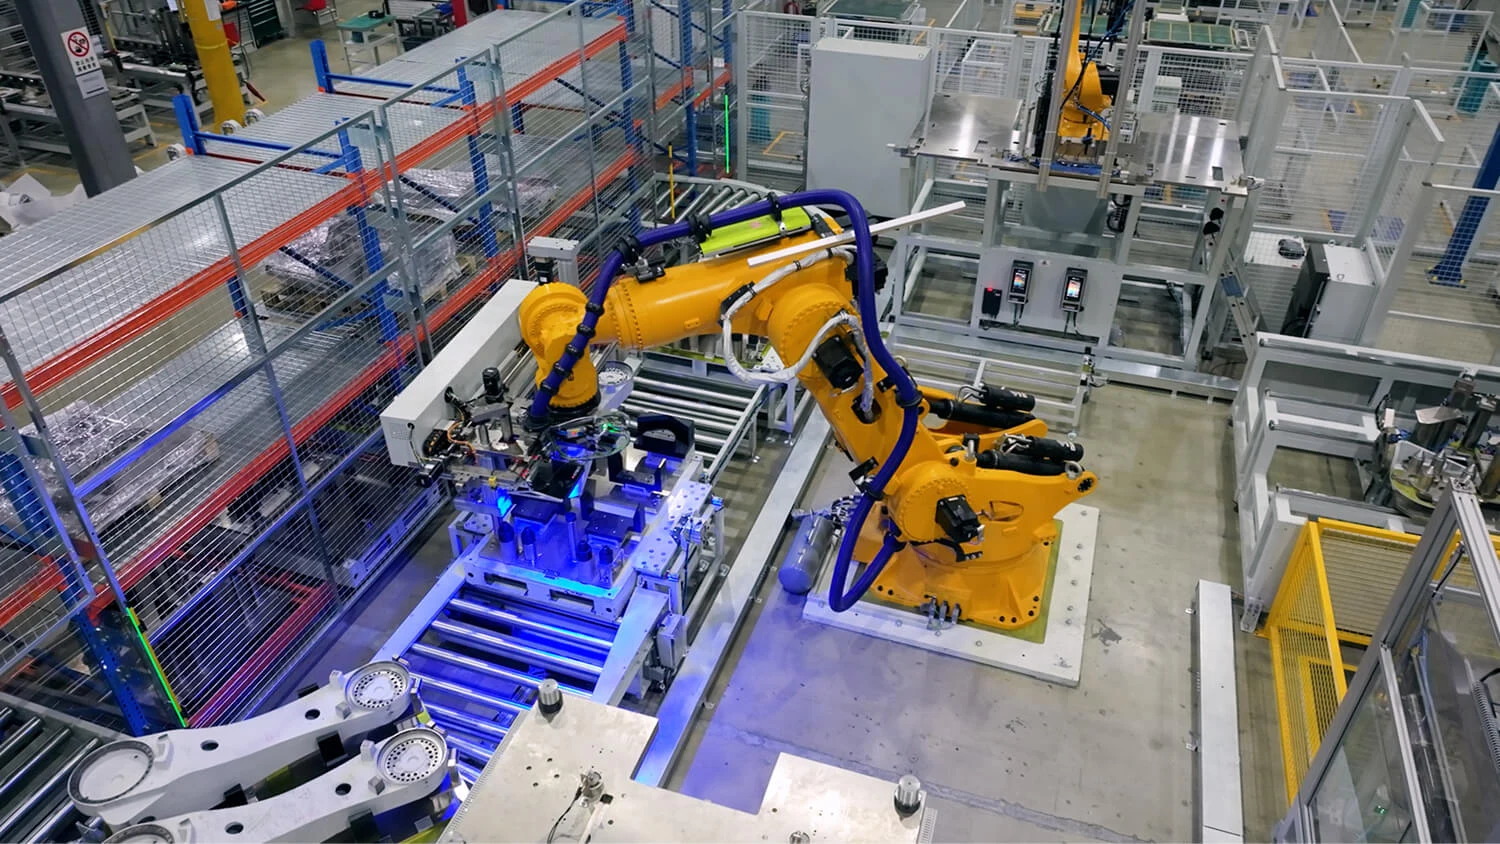
The robot repeats a programmed path. Joint quality also depends on assembly, fixturing, preparation and process settings. A welding study therefore needs to connect robot selection with trials on representative parts.
Define the joint and its variation
Provide assembly drawings, materials, thicknesses, edge preparation and inspection criteria. Describe manufacturing tolerances, gaps and expected distortion. A program developed on one part does not demonstrate its behaviour across the full production range.
Define which operations belong to the cell and which remain upstream or downstream. Tacking, cleaning and any rework need an assigned owner. Trial parts should represent the proposed scope.
Prepare fixturing and access
The fixture should locate the relevant datums and hold the components throughout the intended cycle. Check loading, clamping, torch access, clearance and part removal. Clamps and cables should be represented in the accessibility study.
Consider the states before tacking, after welding and during unloading. Plan checks of locating surfaces and access for fixture cleaning. A part or clamp change may require path changes and renewed trials.
Select the process equipment
ESTUN’s European range includes welding robots with a hollow wrist. This design should be assessed with the torch, cable package and working angles. It establishes neither weld quality nor cell throughput.
Define the power source, wire feeding, consumables, torch maintenance and required positioners with the process specialists. Exchanges between robot, power source and automation should identify commands, confirmations, faults and recovery states.
Run process trials
Before trials, agree which parameters to investigate, the number of parts, inspection methods and how out-of-criteria results will be handled. Record the program version, part preparation, selected settings and trial conditions. Conclusions remain limited to those conditions.
Simulation helps examine access and sequences. ABB presents welding software and welding data collection functions. These documented ABB tools do not establish an equivalent option on an ESTUN configuration without checking what is supplied.
Also define permitted adjustments during trials. Record manual intervention between operations so the result describes the process performed.
Distinguish trials from qualification
Robot repeatability is not a joint inspection result. The trial file should connect each assembly with agreed criteria, inspections performed and their results. Missing measurements remain recorded as not performed.
If the project requires formal process qualification or specific welding documents, identify the applicable framework, authorised personnel, test pieces and required inspections. Cell integration alone does not obtain that qualification.
Set the acceptance scope
Acceptance identifies the part references, fixtures, sequences, settings and inspections included. Trials also cover agreed changeovers and recovery cases. Cell hazard protection requires a risk assessment; Suva’s method includes consideration across the life cycle.
At handover, retain the selected programs and settings, tested part list, agreed maintenance instructions and open reservations. Maintenance and training services are defined in the project quotation.
Common questions
Points to clarify.
Does a welding robot guarantee the weld?
No. The joint depends on the process, assembly and verified conditions. Acceptance relies on agreed inspections.
Can an existing fixture be reused?
Its locating, clamping and access need assessment with the intended torch and parts. The decision follows that assessment.
Is process qualification included?
Its scope, framework and participants must be explicitly included in the quotation. No qualification is assumed.